Key Takeaways & Executive Findings
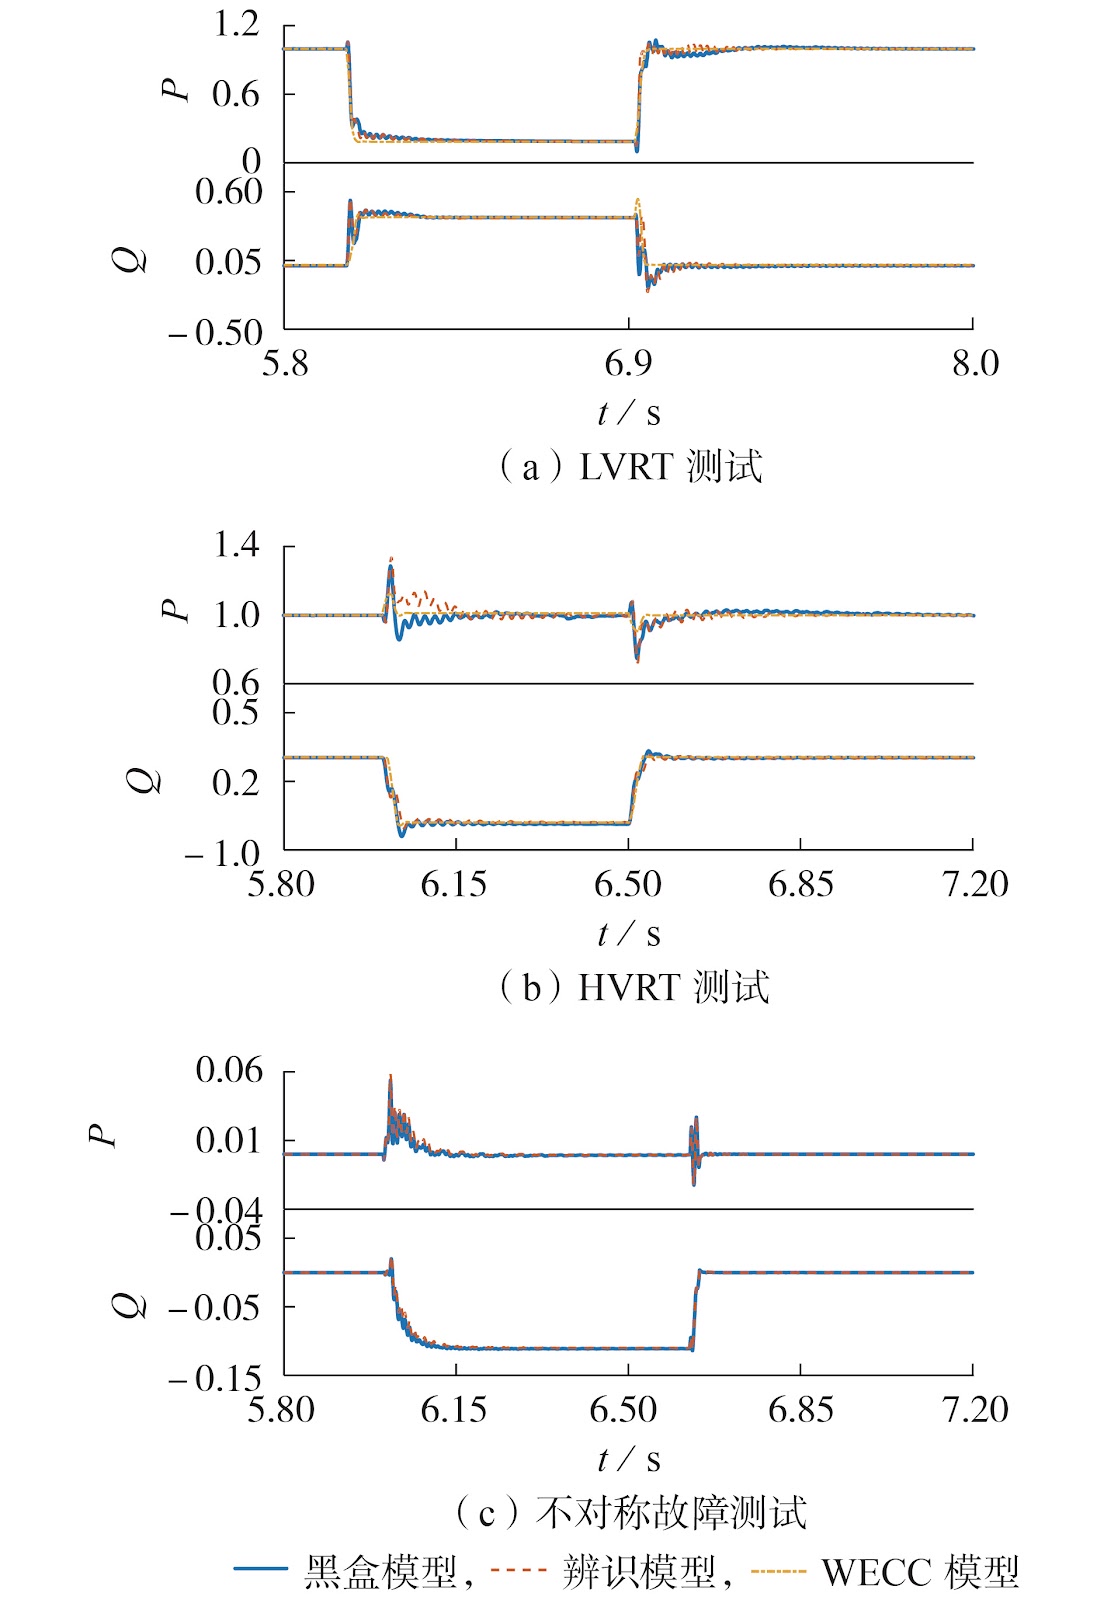
- •• • Identification method validated across 9 mainstream DFIG types under symmetrical and asymmetrical faults with voltage sags from 0.9 to 0.2 p.u. and swells from 1.2 to 1.3 p.u., demonstrating broad adaptability where prior single-structure models fail. • • Fault durations ranging from 500 ms to 2000 ms were tested, covering transient to sustained FRT events; the proposed white-box model accurately reproduces full-process responses, including active power spikes and oscillations at fault inception and clearance. • • The model outperforms the WECC second-generation generic model, which cannot simulate asymmetrical faults or detailed FRT responses, providing a superior basis for EMT simulation of renewable-dominated grids. • • Hardware-in-the-loop validation against manufacturer black-box models and actual controllers confirms high fidelity, enabling controller design optimization, protection strategy verification, and grid integration performance analysis without proprietary data.
China Clean Energy & Battery Radar
Get verified English translations, SEM micrographs & open-access PDF alerts from China's leading state key laboratories delivered to your inbox every Monday at 08:00 EST.
Abstract
Accurate electromagnetic transient (EMT) models of doubly-fed induction generator (DFIG) wind turbines are essential for grid stability analysis under large disturbances, yet encapsulated commercial controllers prevent structural access. This paper proposes a controller structure identification method based on the mapping between fault ride-through (FRT) response morphology and control loop actions. Using measured FRT responses from nine mainstream DFIG types under symmetrical and asymmetrical faults—with voltage sags to 0.9, 0.75, 0.5, 0.35, and 0.2 p.u. and swells to 1.2, 1.25, and 1.3 p.u., and durations of 2000, 1705, 1214, 920, 625, 2000, 1000, and 500 ms—typical response features are categorized. Mapping relationships between each FRT stage and control loop actions are established, and identification criteria for active power, reactive power, and FRT control loops are constructed via excitation signal and operating condition combinations. A white-box EMT model is built from the identification results and validated on a hardware-in-the-loop platform against manufacturer black-box models and actual controllers. Results show the proposed method achieves high modeling accuracy across different DFIG types and operating conditions, outperforming the WECC generic model, particularly in reproducing full-process FRT responses including active/reactive power spikes, oscillations, and recovery behaviors.
1. Introduction
Existing electromagnetic transient (EMT) models of DFIG wind turbines fail to accurately replicate full fault ride-through (FRT) responses, primarily because manufacturer controllers are encapsulated and their structures are treated as core trade secrets. The WECC first-generation generic model cannot simulate FRT, and the second-generation model, while widely used in机电 simulation tools, omits main circuits and partial controllers, precluding asymmetrical fault analysis. Custom black-box models from manufacturers offer high accuracy but are inaccessible for control strategy design, creating a critical bottleneck for grid stability assessment in renewable-heavy power systems.
This paper addresses the structural identification gap by establishing a mapping between FRT response morphology and control loop actions. Measured responses from nine mainstream DFIG types under symmetrical and asymmetrical faults—with voltage sags to 0.2–0.9 p.u. and swells to 1.2–1.3 p.u., and durations of 500–2000 ms—are analyzed to derive identification criteria for active power, reactive power, and FRT control loops. A white-box EMT model is constructed and validated on a hardware-in-the-loop platform against manufacturer black-box models and actual controllers, demonstrating superior accuracy over the WECC model and enabling generic controller structure identification for diverse DFIG types.
Loading authentic research manuscript (Pages 1–5)...
CUI Haohan, CHAO Pupu, LI Weixing (2026). Controller Structure Identification Method for Doubly-Fed Wind Turbine Generators Based on Mapping Between FRT Response and Control Loops. Power Automation Equipment. https://doi.org/10.16081/j.epae.202606015
Research & Educational Purpose Only: The translations, structured abstracts, analytical annotations, and data reports provided by SinoGreenTechare intended exclusively for academic research, internal corporate R&D, and educational benchmarking. They do not constitute formal engineering, chemical safety, legal, or professional advice.
Copyright & Intellectual Property Notice: Original copyright of the underlying source articles and experimental data remains with the respective authors, institutions, and original publishing journals. SinoGreenTech claims intellectual property only over its proprietary translations, analytical syntheses, and AEO structured enhancements in accordance with international fair use and academic citation principles.
Frequently Asked Questions
What specific failure mechanisms in existing DFIG EMT models prevent accurate FRT simulation, and how does the proposed method overcome them?
Existing WECC second-generation models omit main circuits and partial controllers, cannot simulate asymmetrical faults, and assume a single control structure, leading to errors in reproducing active/reactive power spikes, oscillations, and recovery behaviors. The proposed method identifies controller structures by mapping measured FRT responses—such as positive/negative sequence reactive power generation and active power recovery rates—to specific control loops, enabling white-box models that capture full-process dynamics across 9 DFIG types under voltage sags to 0.2 p.u. and swells to 1.3 p.u.
What are the scalability bottlenecks when applying this identification method to a large fleet of diverse DFIG controllers?
The method requires excitation signal and operating condition combinations tailored to each FRT stage, which may increase testing time for units with complex switching logic. However, validation across 9 mainstream DFIG types with fault durations from 500 ms to 2000 ms demonstrates adaptability without hardware modification. The identification criteria for active, reactive, and FRT control loops are generic, reducing per-unit effort. Scalability is further supported by hardware-in-the-loop implementation on DSP, enabling automated batch identification.
How does the proposed white-box model achieve cost parity or performance advantage over proprietary black-box models in industrial deployment?
Black-box models are accurate but inaccessible for control design, requiring expensive reverse-engineering or vendor collaboration. The proposed method delivers a white-box EMT model with accuracy validated against manufacturer black-box models and actual controllers on a HIL platform, eliminating licensing or proprietary barriers. It outperforms the WECC model, which is free but inaccurate for asymmetrical faults and detailed FRT responses. The identification process uses standard test signals and can be integrated into existing DSP-based controller development workflows, reducing long-term costs for grid operators and turbine manufacturers.
What are the limitations of the identification method under extreme fault scenarios, such as very low voltage ride-through below 0.2 p.u. or fast transients?
The method was validated for voltage sags down to 0.2 p.u. and swells up to 1.3 p.u., with fault durations as short as 500 ms. For sags below 0.2 p.u., additional excitation conditions may be needed to capture nonlinearities in current limiting and protection activation. Fast transients at fault inception and clearance are captured via spike and oscillation features in the mapping, but sampling rates and signal processing must be adequate. The HIL validation confirms robustness for tested ranges; extension to deeper sags requires further testing but the framework is adaptable.
How does the method handle negative-sequence control loops, which are critical for asymmetrical fault ride-through?
The mapping explicitly includes negative-sequence reactive power responses, such as generation following negative-sequence voltage rise. Identification criteria for negative-sequence control loops are constructed using asymmetrical fault tests (e.g., two-phase voltage sags) with negative-sequence components extracted. The method successfully identified controllers that emit negative-sequence reactive power, as observed in measured responses from 9 DFIG types. This enables accurate simulation of asymmetrical faults, a capability absent in WECC models.
Related Chinese Research & Cross-Citations
Impedance Modeling and Parameter Optimization Method for Wind Farms Considering Station-Level Control
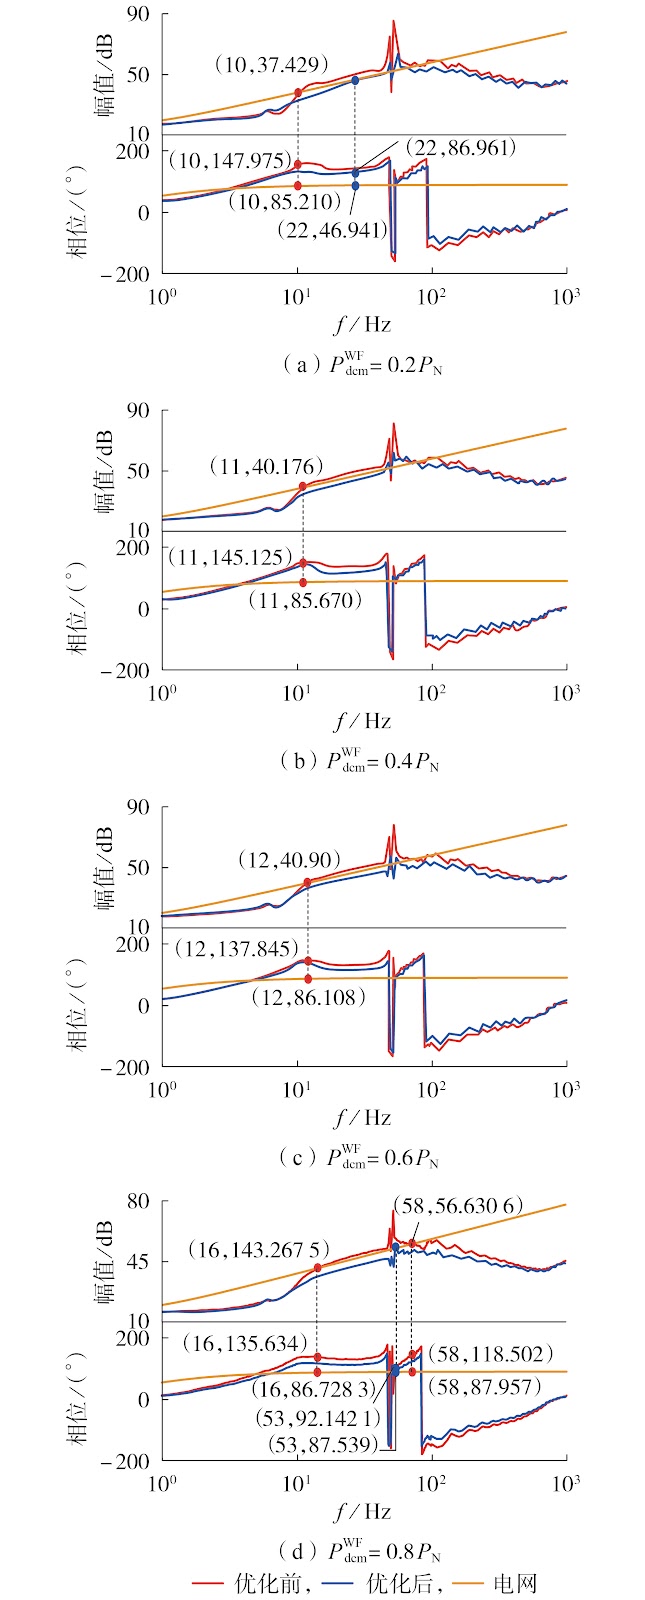
Large-scale wind farms integrated into weak grids are susceptible to broadband oscillations, a problem that existing impedance models and control parameter optimization methods fail to address systematically because they neglect station-level control and frequency coupling effects. This paper proposes a station-level control strategy based on available power allocation and an adaptive compass search (ACS) algorithm for optimizing station control parameters. A sequence impedance method incorporating frequency coupling effects establishes the aggregated wind farm impedance, and the grid-connected multiple-input multiple-output (MIMO) system is decoupled into positive- and negative-sequence single-input single-output (SISO) impedance models. A high-precision wind farm impedance model that accounts for station-level control is constructed, and the Nyquist criterion evaluates the suppression effect of station control on broadband oscillations. The ACS algorithm optimizes station control parameters to enhance the adaptability of wind farm impedance to external grid impedance, thereby reducing oscillation risk. RT-LAB platform simulations validate the impedance modeling method and control parameter optimization. Results demonstrate that considering station-level control yields a high-precision wind farm impedance model. Compared with genetic algorithm (GA), particle swarm optimization (PSO), grey wolf optimizer (GWO), and sparrow search algorithm (SSA), ACS is more suitable for optimizing wind farm control parameters. Under specific weak-grid conditions, ACS-optimized station control parameters effectively improve grid-connected stability of the wind farm.
Active and Reactive Power Coordinated Voltage Support Control Method for High-Inertia Energy-Storage Synchronous Condenser
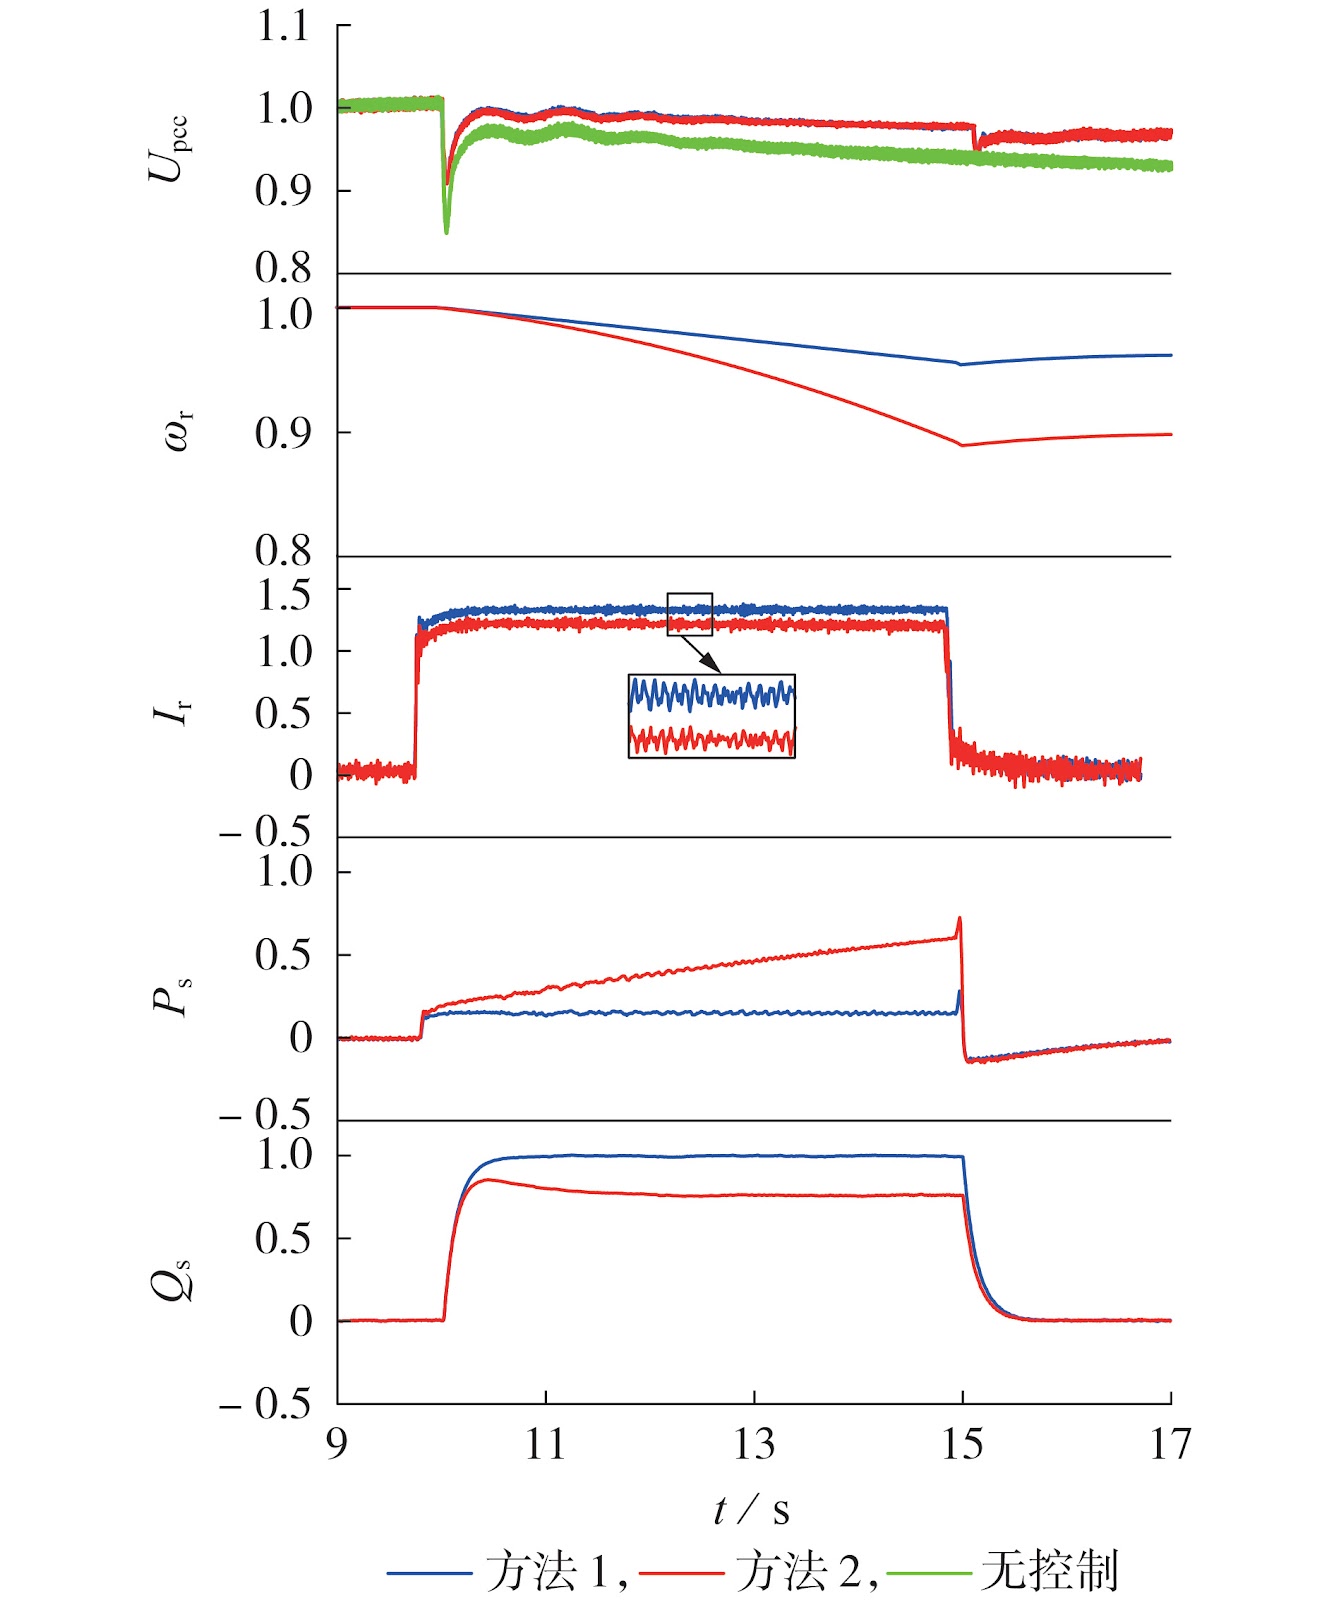
The high-inertia energy-storage synchronous condenser (SC-HI-ES) can provide reactive power support by adjusting excitation current and active power support by actively varying rotor speed. However, the absence of a prime mover makes its control capability difficult to quantify, preventing coordinated active and reactive power support for grid voltage. This paper analyzes the factors influencing SC-HI-ES power control capability, derives rotor current equations considering stator and rotor circuit constraints, and establishes the power controllable range (PCR) under rotor current constraints and speed variations. The relationship between the PCR and voltage support power demand is parsed, and a coordinated active-reactive power voltage support control method is proposed. Case studies validate the method's effectiveness. Results show that the proposed method enhances voltage support and avoids rotor current over-limit. Compared with methods ignoring speed variation or controlling only reactive power, the proposed method dynamically calculates PCR-based power demand under current speed, and through coordinated active and reactive power control, maximally satisfies the point of common coupling voltage target while ensuring rotor current does not exceed allowable values. This provides effective technical support for SC-HI-ES application in new-type power systems. Frequency control capability characterization and frequency-coordinated control are identified as future research directions.
Hardware-in-the-Loop Test Platform for Photovoltaic High-Frequency Controllers Based on UREP + FPGA
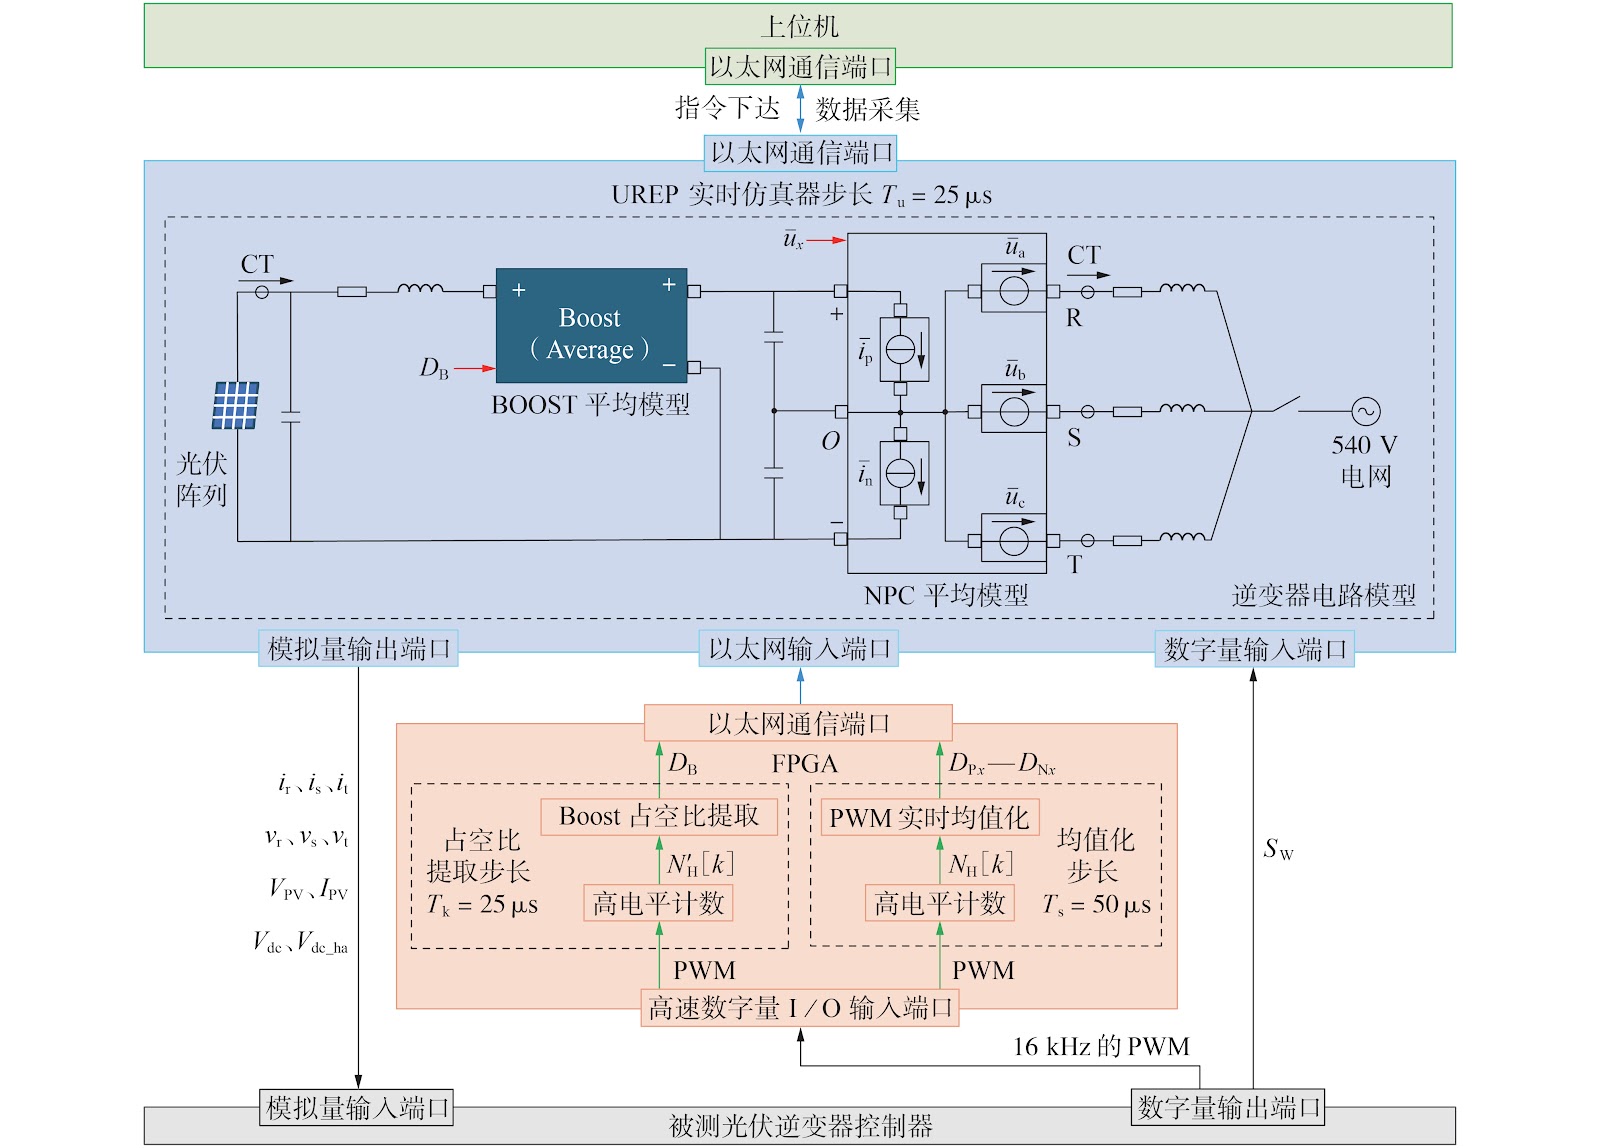
Real-time constraints prevent CPU-based electromagnetic transient simulators from accurately sampling high-frequency PWM signals at microsecond step sizes, leading to insufficient HIL test precision and even instability of the closed-loop system. This paper introduces a PWM averaging technique to construct a novel UREP (electromagnetic transient real-time simulator) + FPGA hardware-in-the-loop test platform. To achieve accurate PWM acquisition, the FPGA's nanosecond-level clock resolution increases the number of sampling points within a single switching period from a few points under microsecond simulation steps to several thousand points. The FPGA implements fixed-step PWM averaging, converting discrete switching states into continuous duty cycles that serve as control signals for the UREP-side inverter average model. This technique avoids frequent topology updates and state matrix reconstructions triggered by switching events, reduces high real-time computational resource consumption, improves numerical stability of the in-loop system, and enhances HIL test accuracy under large-step real-time constraints. Simulation cases and industrial-grade controller HIL tests verify the platform's feasibility and accuracy. The platform provides an efficient, reproducible verification scheme for photovoltaic controller control strategies and offers a feasible technical path for domestic electromagnetic transient real-time simulation platforms to conduct high-frequency controller HIL tests.
Design and Implementation of a Distributed Simulation Architecture for Modern Power Systems Based on Data Distribution Service
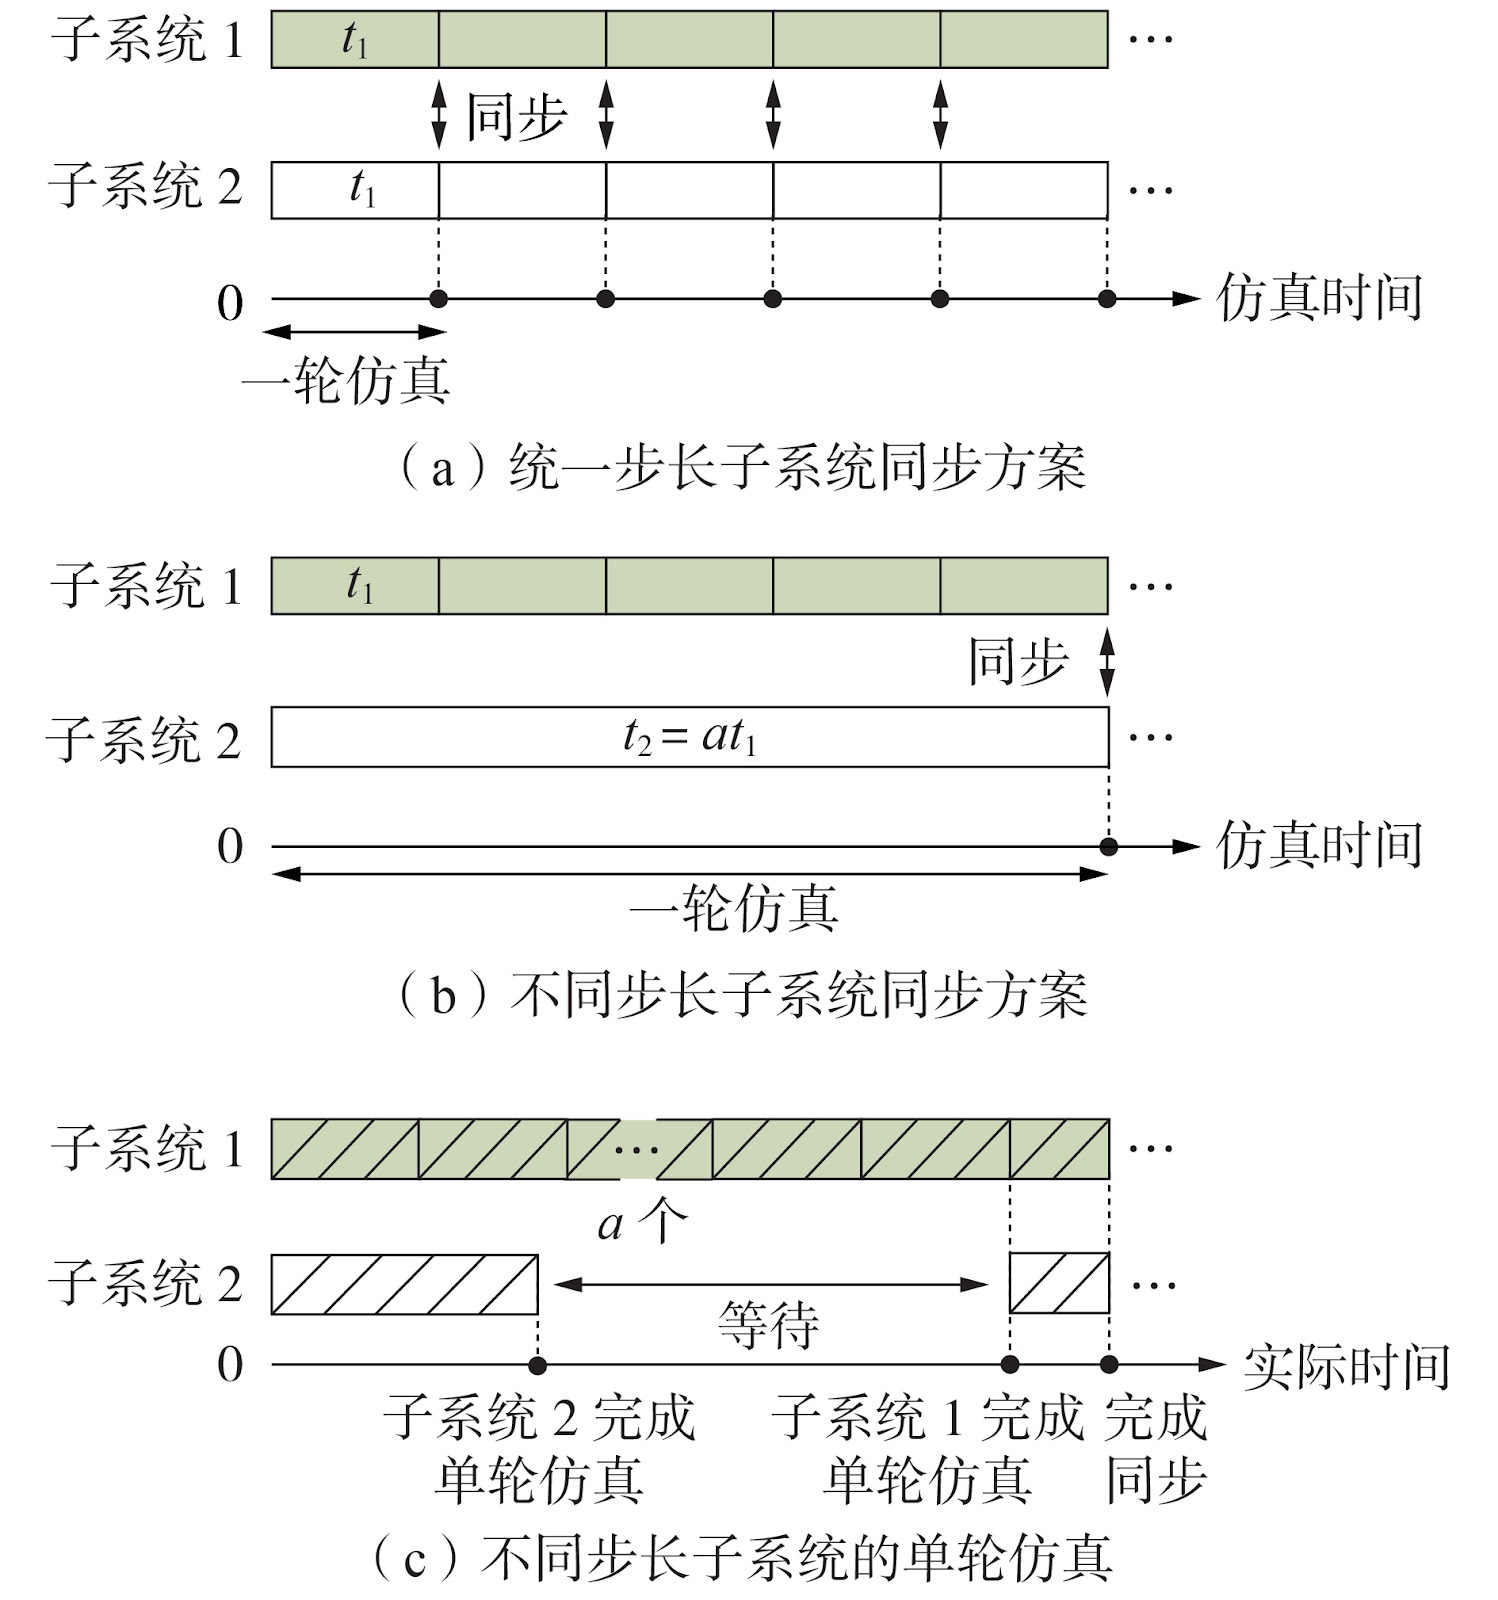
The integration of high-penetration renewable energy and power electronic converters has intensified the dynamic complexity of modern power systems, imposing stringent demands on simulation accuracy and computational efficiency. This paper proposes a distributed simulation architecture based on Data Distribution Service (DDS) that leverages dispersed computing resources to enhance scalability and efficiency while preserving numerical fidelity. The power system model is mathematically decoupled into multiple independently solvable basic subsystems, and a generic data transmission interface is designed using DDS. A time-consumption balancing scheme groups and distributes these subsystems across multiple devices, and a two-layer synchronization strategy enables efficient parallel simulation. The architecture is validated on a two-area four-machine system, the IEEE New England 10-machine 39-bus system, and the WECC 29-machine 179-bus system. Compared with centralized simulation, the average error on the two-area four-machine system remains below 1.05%. Simulation efficiency improvement reaches approximately 10% on the 10-machine 39-bus system and about 48% on the 29-machine 179-bus system. The results confirm high accuracy across different system scales and demonstrate that efficiency gains become more pronounced as system size increases, validating the architecture's scalability and compatibility. The proposed framework offers a promising pathway for large-scale power system simulation and supports future integration with edge computing and cross-platform deployment.
Heterogeneous Weighted Graph Partitioning and Decoupling Optimization Strategy for Electromagnetic Transient Parallel Simulation of AC/DC Distribution Networks
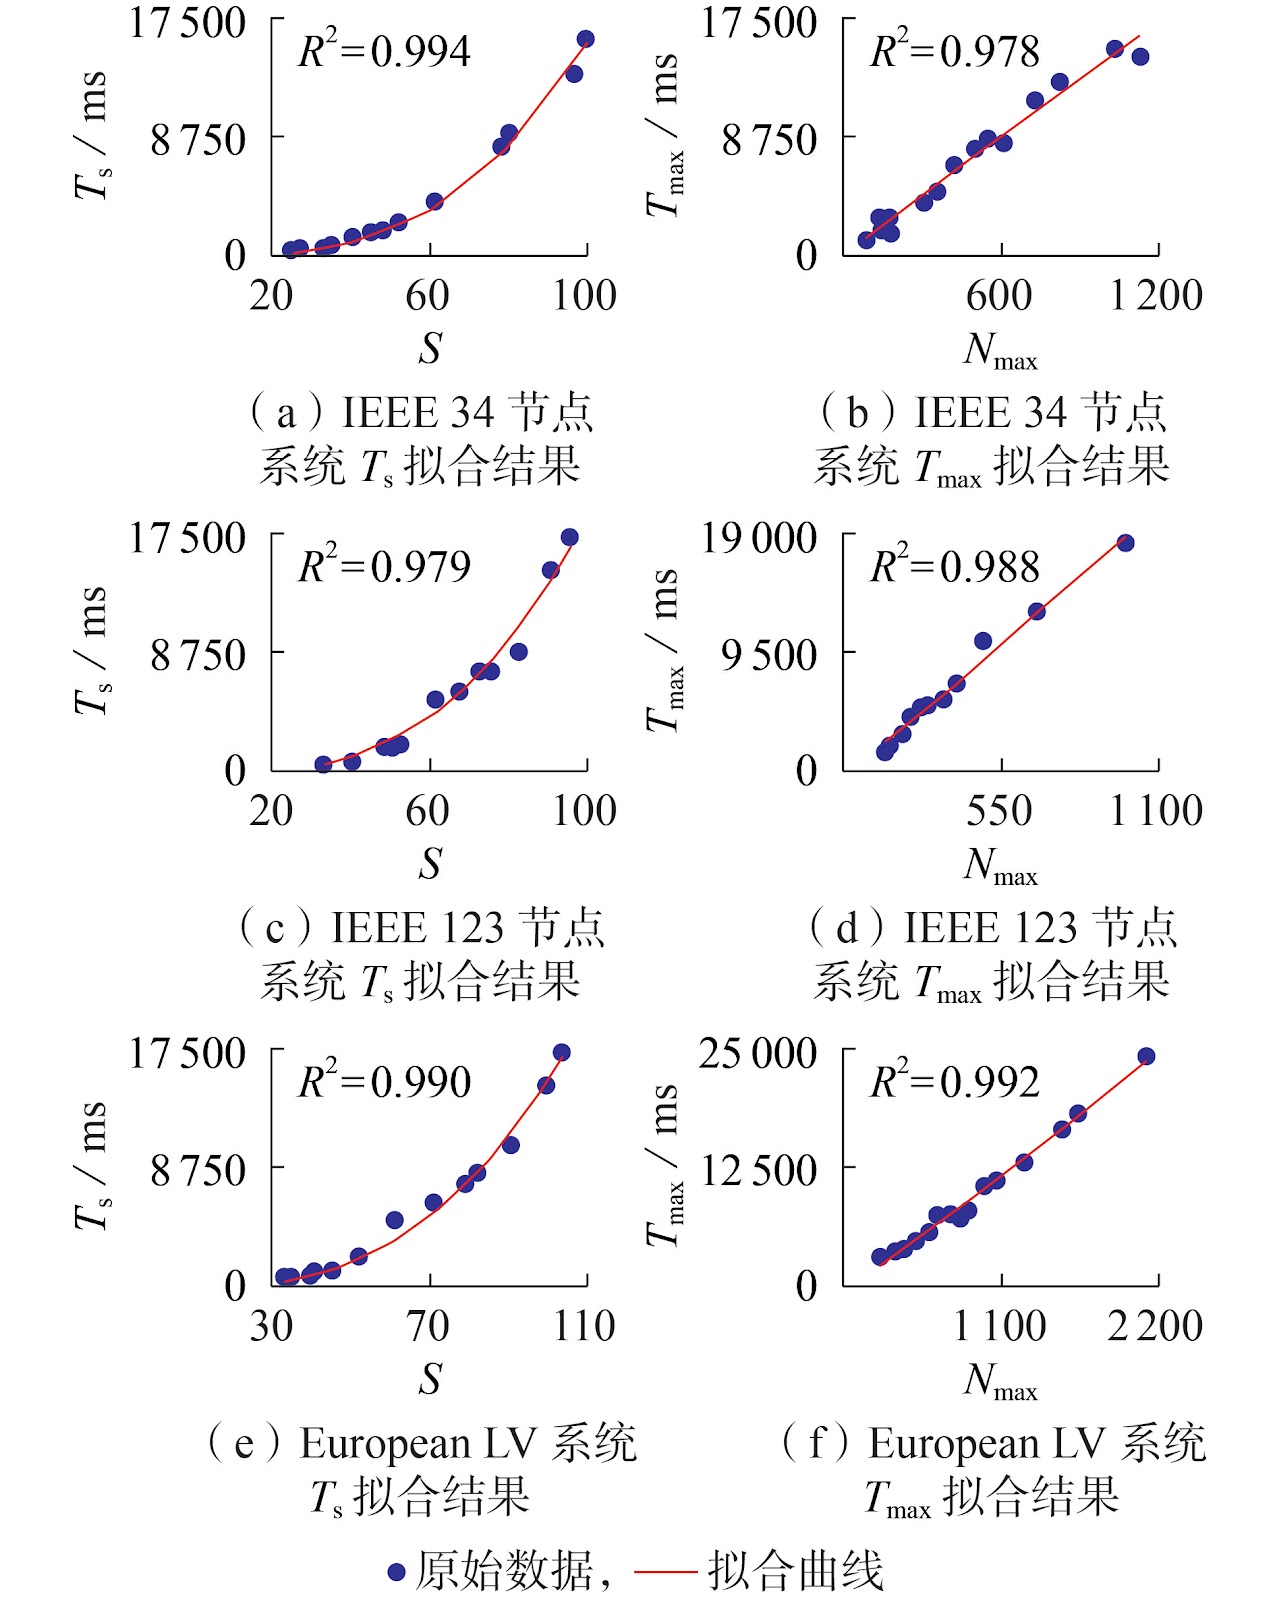
The increasing penetration of power electronic devices in AC/DC distribution networks imposes stringent computational demands on electromagnetic transient (EMT) parallel simulation. Conventional transmission-line delay decoupling methods are ill-suited to the strong electrical coupling characteristic of such networks. This paper proposes a non-delay decoupling parallel simulation acceleration framework based on heterogeneous weighted graph partitioning. An empirical computational cost evaluation model for each parallel decoupling stage is established, and a heterogeneous weighted graph model is constructed to precisely characterize the simulation computational complexity of AC/DC distribution network components, mapping matrix dimensions of device mathematical models to graph node weights. A multi-objective graph partitioning scheme is formulated that simultaneously balances partition computational overhead and minimizes the number of tie-line variables, complemented by an optimal partition number screening strategy. Simulation validation is conducted on three large-scale AC/DC distribution network composite test cases: IEEE 34-node, IEEE 123-node, and European Low Voltage (European LV) systems, all retrofitted with DC sections. Results demonstrate that the proposed empirical computational cost model achieves a simulation time fitting goodness-of-fit R² > 0.97, indicating high predictive accuracy. Under optimal partition configuration, the proposed method attains parallel speedup ratios of 12.11–15.77, significantly outperforming conventional natural partitioning schemes and effectively enhancing the EMT parallel simulation efficiency of AC/DC distribution networks.
Hierarchical Hybrid Non-Delay Decoupling Parallel Method for Electromagnetic Transient Simulation of DC-Collector Offshore Wind Farms
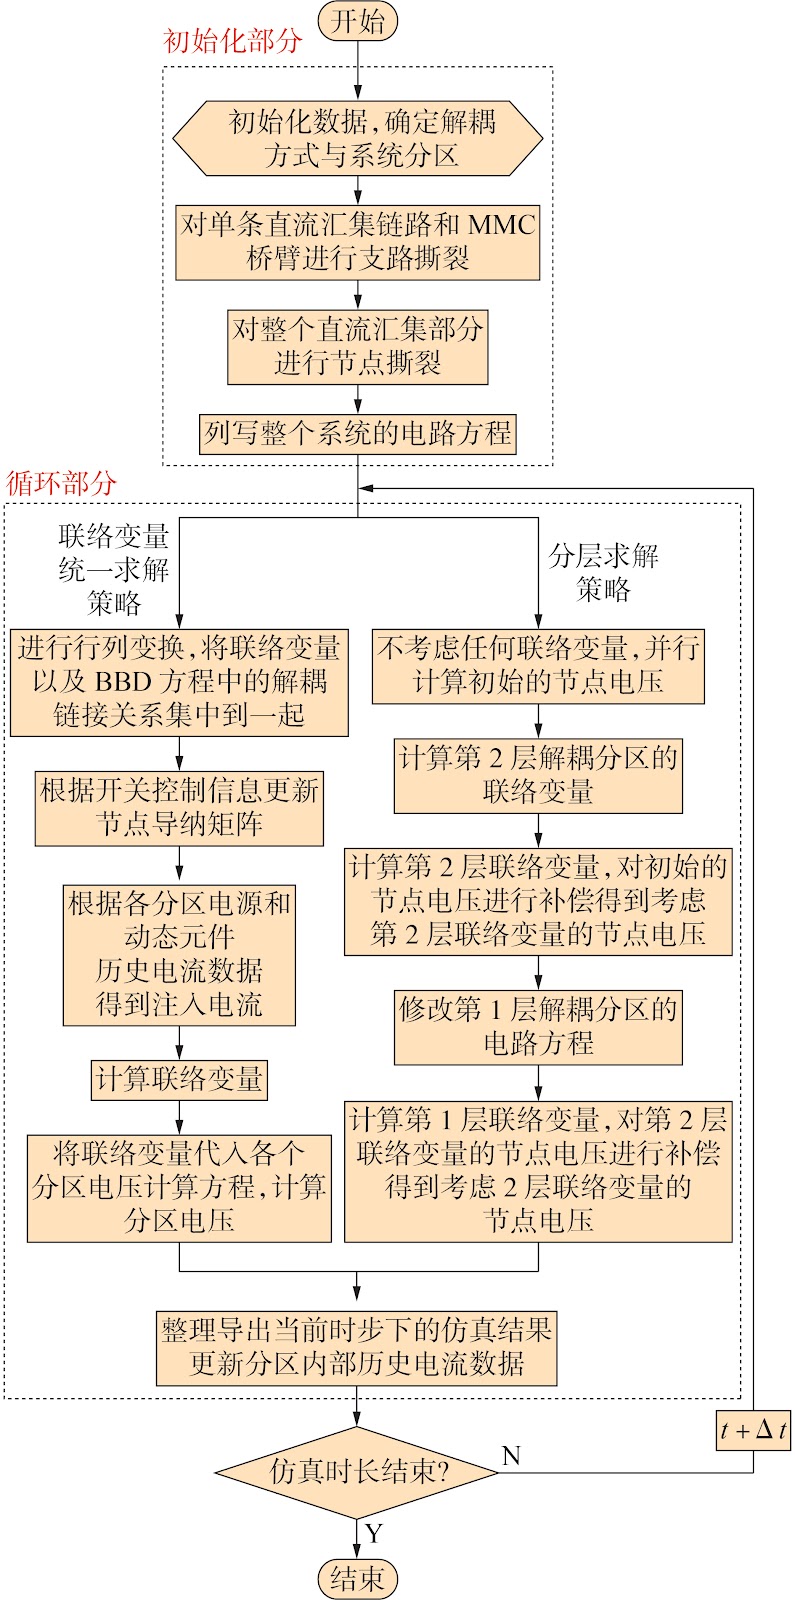
Real-time electromagnetic transient (EMT) simulation of DC-collector offshore wind farms is constrained by microsecond time steps, high model order from cascaded power electronic converters, and the inability of conventional decoupling methods to handle complex series-parallel topologies without introducing artificial delays. Existing non-delay decoupling methods, such as multi-area Thevenin equivalence (MATE) and compensation method, rely on branch tearing and are ill-suited for systems with numerous common-bus partitions, leading to excessive link variables and singular admittance matrices. This paper proposes a hierarchical hybrid non-delay decoupling parallel method that integrates MATE and its dual (node-tearing) approach through a layered architecture. The method constructs a mixed equivalent model tailored to DC-collector offshore wind farms, enabling flexible selection between unified and hierarchical solution modes for link variables based on operating conditions. A complete non-delay decoupling simulation workflow is established and validated on a DC series-parallel grid-connected offshore wind farm test case implemented in MATLAB. Results demonstrate that the proposed method reduces solution matrix dimensions and achieves significant speedup without compromising accuracy. For a 96-turbine wind farm, the hybrid decoupling model achieves an 11.99x speedup over the detailed model, compared to 8.77x for series-only decoupling and 6.22x for parallel-only decoupling. Mean absolute errors (MAE) for key variables remain below 0.1011, and root mean square errors (RMSE) below 0.6318, confirming high fidelity. The method enhances parallel simulation performance and offers a generalizable solution for real-time EMT simulation of large-scale offshore wind farms.