Key Takeaways & Executive Findings
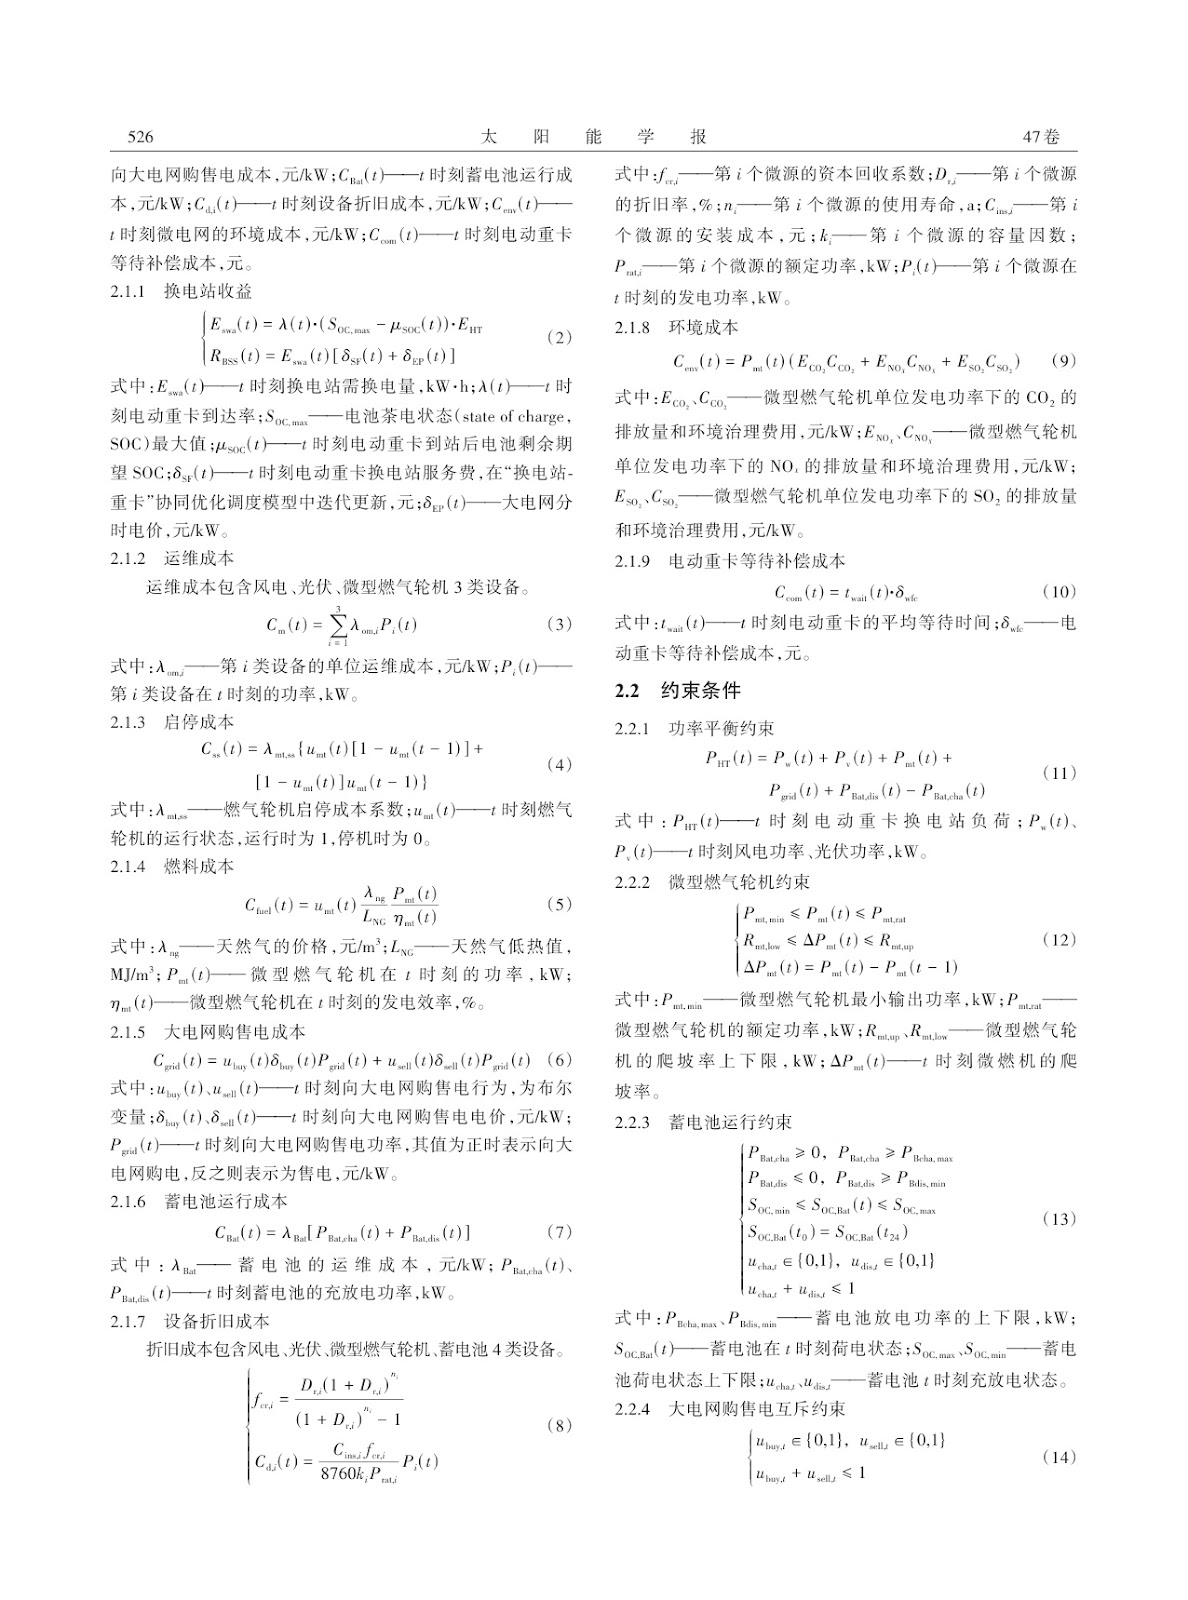
- •• • The tri-layer model discretizes charging into 15-minute intervals, enabling CPLEX to solve the microgrid mixed-integer linear program while the antelope optimization algorithm handles the BSS-truck subproblem; this decomposition matters industrially because monolithic stochastic formulations for coupled vehicle-grid systems typically exceed tractable solve times beyond 96 intervals. • • Service fee adjustment is the sole control lever for reshaping truck arrival rates; the BSS layer optimizes charging power to track renewable output and balance supply-demand, then translates that schedule into a fee signal. This indirect mechanism avoids direct command-and-control over drivers, a critical design constraint for commercial fleet operations where driver autonomy is contractually protected. • • The objective function F1 maximizes net revenue by subtracting eight cost terms—operation and maintenance, gas turbine start-stop, fuel, grid purchase, battery degradation, waiting compensation, environmental, and communication—from BSS revenue. The explicit inclusion of waiting compensation cost (Cd,i) ties driver inconvenience to system economics, a parameter absent from prior BSS dispatch models that treated queue time as exogenous. • • The framework assumes uniform battery specifications across trucks and station inventory, constant charging power, and fixed cost parameters over the optimization horizon. These simplifications enable deterministic solution but exclude battery degradation heterogeneity and market price volatility; industrial deployment would require receding-horizon updates to cost coefficients at minimum daily frequency.
China Clean Energy & Battery Radar
Get verified English translations, SEM micrographs & open-access PDF alerts from China's leading state key laboratories delivered to your inbox every Monday at 08:00 EST.
Abstract
The integration of electric heavy-duty truck battery swap stations (BSSs) into microgrids introduces a bidirectional coupling between renewable generation volatility and swap demand that existing dispatch frameworks fail to capture. This study formulates a tri-layer collaborative optimal scheduling model spanning the microgrid, the battery swap station, and the heavy-duty truck fleet. The microgrid layer maximizes daily revenue by co-optimizing microgas turbine, battery storage, wind, and photovoltaic outputs, with CPLEX resolving the mixed-integer linear program. The BSS layer adjusts service fees to influence truck arrival rates, thereby reshaping the station load profile to track renewable generation. The truck layer responds to fee signals by autonomously selecting swap times, with a 15-minute discretization interval. An antelope optimization algorithm solves the BSS-truck subproblem, and the two layers iterate until convergence. The framework is validated against a case study, demonstrating that fee-mediated demand response reduces curtailment and improves supply-demand balance. The model addresses a critical gap: prior BSS scheduling treated arrival rates as exogenous and ignored renewable fluctuations, while truck swap decisions ignored station service capacity. By internalizing both signals, the proposed architecture achieves coordinated optimization without centralized control over vehicle behavior.
1. Introduction
Heavy-duty truck electrification confronts a fundamental mismatch: battery swap stations (BSSs) schedule charging based on historical arrival rates, while microgrid operators dispatch renewable generation without visibility into swap demand. Prior work optimized microgrid scheduling with cost and emissions objectives, and separately optimized BSS peak-shaving under service capacity constraints, but no framework closed the loop between renewable volatility and truck swap timing. The consequence is predictable—curtailment during high-wind or high-solar periods coinciding with low swap demand, and grid purchases during peak periods when trucks arrive en masse.
This study introduces a tri-layer collaborative architecture where the microgrid broadcasts renewable generation forecasts to the BSS, the BSS translates those forecasts into service fee adjustments, and trucks respond by shifting swap times. The BSS-truck subproblem iterates until convergence, with the BSS recalculating charging power after each truck arrival update. CPLEX solves the microgrid layer, and an antelope optimization algorithm solves the BSS-truck layer. The protocol specifically addresses the bottleneck of exogenous arrival rates by making truck behavior endogenous to renewable availability, without requiring direct control over vehicle movements.
Loading authentic research manuscript (Pages 1–5)...
ZHAO Wenfei, YU Guochen, LAN Tianxiao, LI Chunyu, FU Jiajia, QI Zhiyuan (2026). Collaborative Optimal Scheduling of Microgrids Incorporating Electric Heavy-Duty Truck Battery Swap Stations. Acta Energiae Solaris Sinica. https://doi.org/10.19912/j.0254-0096.tynxb.202608_9710
Research & Educational Purpose Only: The translations, structured abstracts, analytical annotations, and data reports provided by SinoGreenTechare intended exclusively for academic research, internal corporate R&D, and educational benchmarking. They do not constitute formal engineering, chemical safety, legal, or professional advice.
Copyright & Intellectual Property Notice: Original copyright of the underlying source articles and experimental data remains with the respective authors, institutions, and original publishing journals. SinoGreenTech claims intellectual property only over its proprietary translations, analytical syntheses, and AEO structured enhancements in accordance with international fair use and academic citation principles.
Frequently Asked Questions
What prevents the service fee mechanism from creating oscillatory arrival rates that destabilize the BSS-truck iteration?
The model iterates between the BSS charging power optimization and truck arrival rate updates until a termination condition is met. Oscillation risk depends on the fee elasticity of truck arrival rates, which is not parameterized in the extracted text. In practice, convergence requires that the fee adjustment step be bounded and that truck response exhibit diminishing sensitivity as fees deviate from a reference level. The 15-minute discretization limits the number of decision points per day to 96, which caps the iteration space and reduces the likelihood of limit cycles. Industrial deployment would require real-time monitoring of arrival rate variance and adaptive damping of fee adjustments if variance exceeds a threshold.
How does the model handle the case where a truck arrives at the BSS but no charged battery is available due to renewable-driven charging delays?
The extracted text does not specify a battery inventory constraint or a service-level guarantee. The waiting compensation cost Cd,i(t) is included in the microgrid objective, which implies that truck waiting time is penalized economically. However, the model assumes uniform battery specifications and constant charging power, which simplifies inventory dynamics. A real system would require a minimum state-of-charge inventory constraint to prevent service failures. The absence of this constraint in the extracted formulation suggests the model assumes sufficient battery inventory or that waiting compensation is sufficient to deter arrivals during low-inventory periods.
What is the computational burden of solving the microgrid MILP with CPLEX at 15-minute resolution over a 24-hour horizon?
The extracted text does not report solve times or problem dimensions. The microgrid layer includes binary variables for gas turbine start-stop decisions and continuous variables for battery, wind, photovoltaic, and grid power. At 96 time steps, the MILP size is moderate—likely solvable within minutes on standard hardware. The BSS-truck layer uses an antelope optimization algorithm, a metaheuristic that may require multiple iterations. The critical computational risk is the outer iteration between layers, which multiplies solve time by the number of convergence rounds. For industrial deployment, a rolling horizon with warm-start initialization would be necessary to meet real-time dispatch requirements.
How sensitive is the revenue maximization to the waiting compensation cost coefficient, and what happens if drivers value time nonlinearly?
The extracted text states that waiting compensation cost is solely a function of waiting time, implying a linear relationship. If drivers value time nonlinearly—for example, with a threshold beyond which dissatisfaction spikes—the linear model would underestimate the fee adjustment needed to shift arrivals. The objective function F1 subtracts Cd,i(t) from revenue, so underestimating compensation cost would lead to overestimating net revenue and under-adjusting fees. Industrial validation would require discrete-choice experiments to estimate the actual utility function of truck drivers, which may vary by fleet operator and route type.
What is the failure mode when renewable generation forecast error exceeds the BSS load flexibility?
The model assumes renewable generation is known and broadcasts it to the BSS. If forecast error is large, the BSS may adjust fees to attract or defer trucks, but truck arrival rates cannot change instantaneously—drivers have schedules and route constraints. The extracted text does not include a forecast error scenario or a robustness constraint. In practice, when forecast error exceeds the BSS load flexibility, the microgrid must fall back on battery storage and gas turbine generation, increasing cost and emissions. The model's deterministic formulation would need stochastic or robust optimization extensions to quantify this failure mode.
Related Chinese Research & Cross-Citations
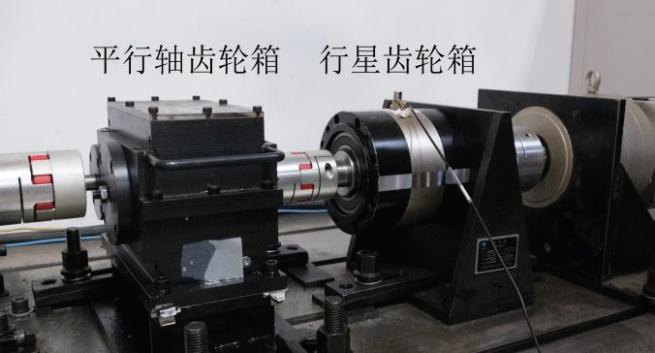
Wind Turbine Gearbox Fault Diagnosis Method Based on Improved CNN-XGBoost Fusion Model Under Gramian Angular Difference Field
Gearbox failures account for 20–30% of total wind turbine faults and incur maintenance costs equivalent to 10–15% of overall turbine value. Conventional vibration diagnostic pipelines—complementary ensemble empirical mode decomposition with singular value energy spectrum, time-varying filtering empirical mode decomposition, and Teager energy spectrum analysis—remain bounded below 90% accuracy and depend on expert-driven feature engineering that is sensitive to non-stationary operating conditions and noise. This study proposes an intelligent diagnostic architecture that converts one-dimensional gearbox vibration signals into two-dimensional images via Gramian angular difference field (GADF) transformation, preserving intrinsic temporal correlation and time-frequency structure while exploiting matrix sparsity to suppress interference. An improved convolutional neural network (CNN) extracts multi-dimensional features: a convolutional block attention module (CBAM) is embedded in the convolutional layers to weight critical channels and focus on fault-sensitive spatial regions, and a modified βc-ACONC activation function replaces ReLU to mitigate neuron necrosis and enable selective activation. The extracted composite features are then fed into an XGBoost network whose hyperparameters are optimized by an improved sparrow search algorithm (ISSA). Validation on a laboratory wind turbine gearbox dataset yields diagnostic accuracy exceeding 99%, demonstrating robust fault identification capability under complex operating conditions.
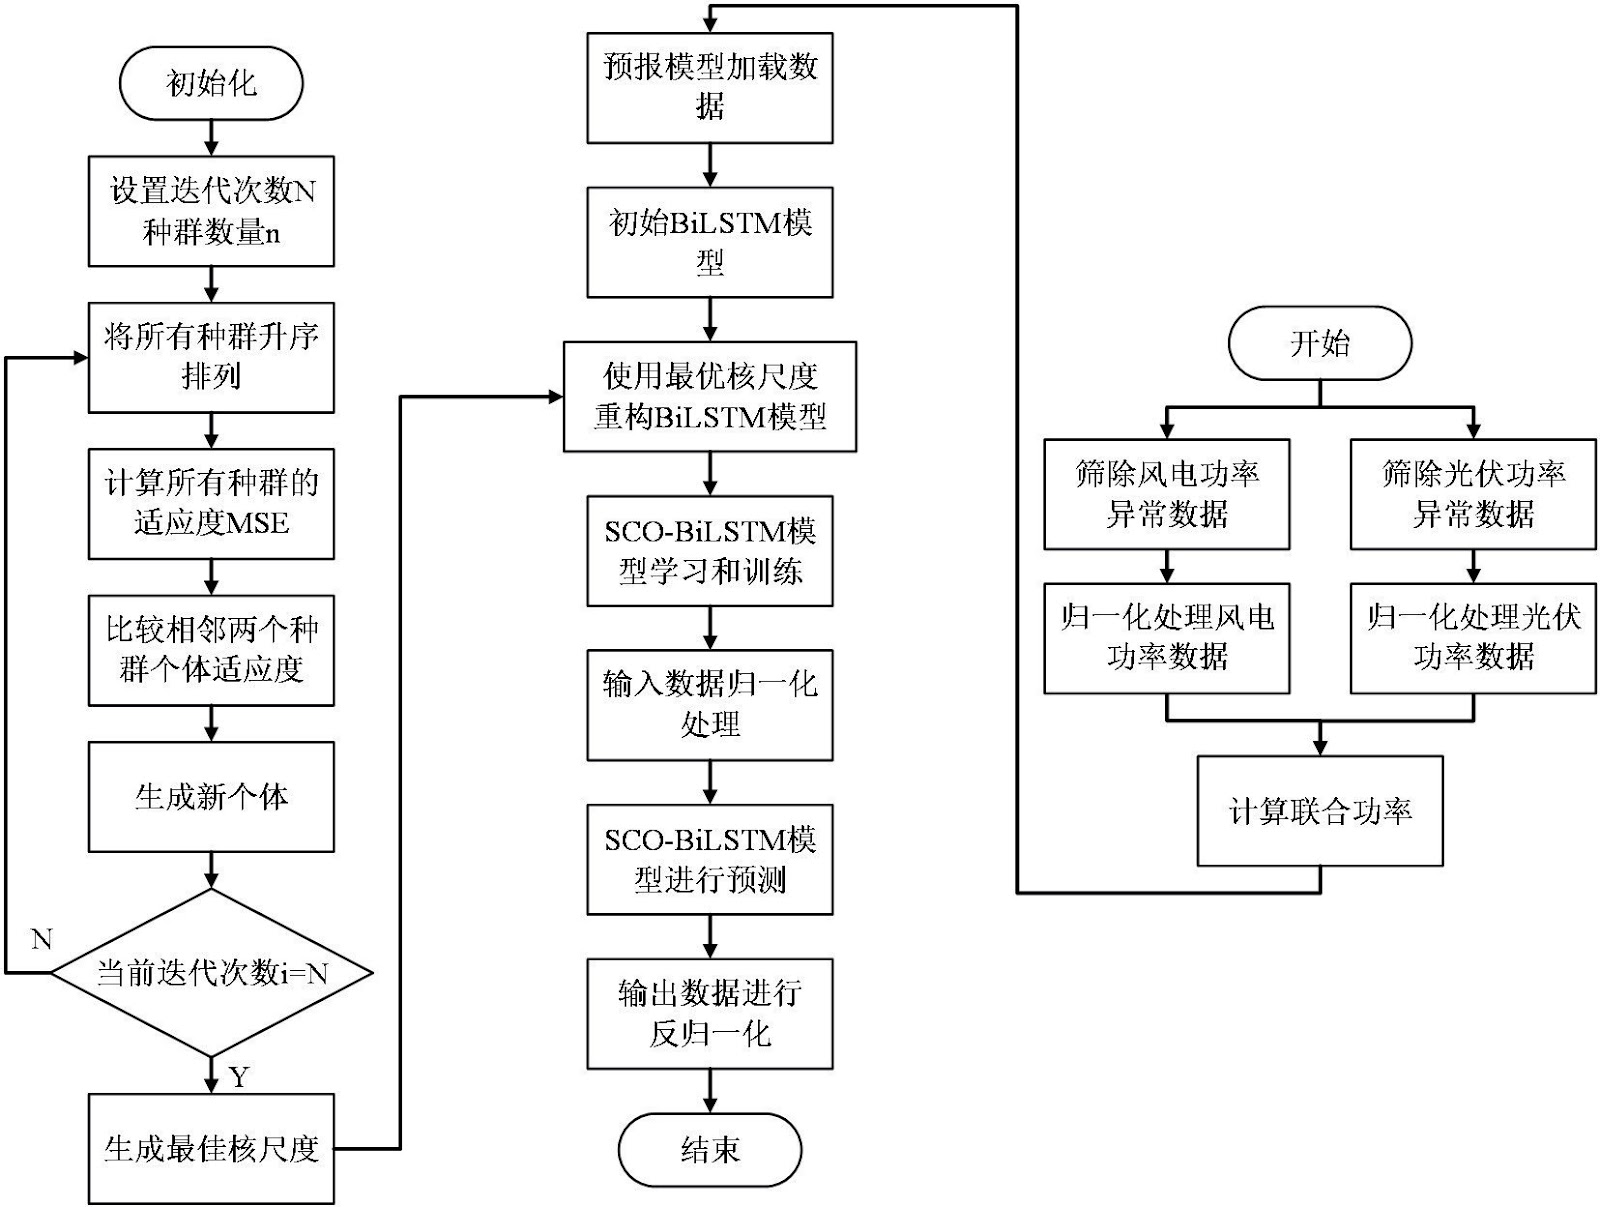
Joint Forecasting of Wind and Photovoltaic Power Considering Complementarity
The inherent spatiotemporal complementarity between wind and solar resources offers a theoretical basis for improving renewable power forecasting accuracy. This study proposes a joint wind-photovoltaic (PV) power forecasting strategy that explicitly exploits this complementarity. A bidirectional long short-term memory (BiLSTM) neural network serves as the baseline forecasting model, and a novel sorting and comparative optimization (SCO) algorithm is developed to optimize the model's hyperparameters. The SCO algorithm ranks individuals in ascending order and compares adjacent fitness values to escape local optima, a known deficiency in conventional metaheuristics such as genetic algorithms and particle swarm optimization. For wind farms and PV plants exhibiting significant complementarity, the joint forecasting strategy first aggregates their power outputs, normalizes the combined signal, and then feeds it into the optimized BiLSTM model. Experimental results demonstrate that the proposed SCO-BiLSTM model reduces the eMAPE by 10.313% compared with PSO-BiLSTM. Furthermore, joint forecasting under SCO-BiLSTM lowers the eRMSE by 27.443% relative to standalone PV power forecasting. The study also establishes that forecasting accuracy improves with stronger wind-solar complementarity but degrades as the forecasting horizon extends. These findings confirm that exploiting complementarity in joint forecasting substantially enhances predictive performance for renewable energy integration.
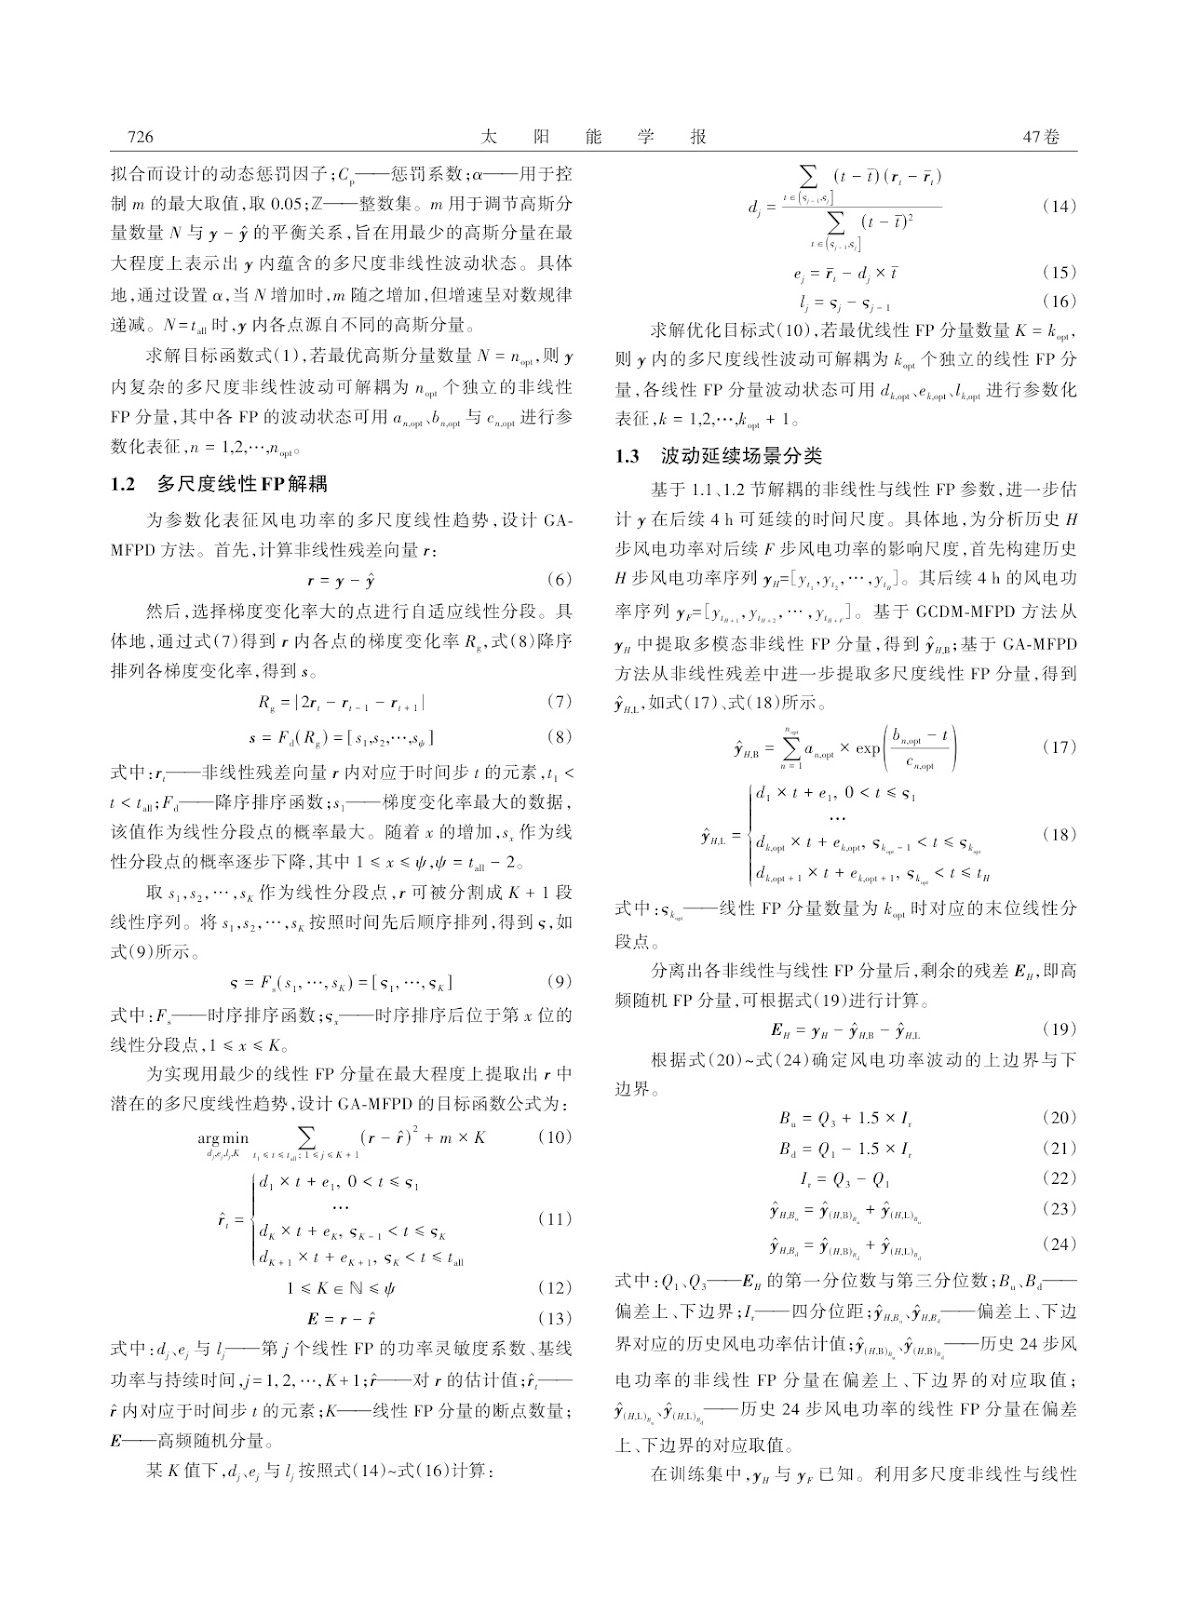
Ultra-Short-Term Wind Power Forecasting Based on Fluctuation Continuation Scenario Identification
Existing ultra-short-term wind power forecasting methods exhibit limited performance due to insufficient extraction of fluctuation information and inadequate analysis of evolution patterns. This paper proposes an ultra-short-term wind power forecasting method based on fluctuation continuation scenario identification. First, the coupling mechanism of wind power fluctuations under multiple turbulence processes is investigated, and historical wind power dynamics are decoupled into a combination of nonlinear and linear fluctuation components. A fluctuation continuation concept is introduced, and the future continuation scale of wind power fluctuations is derived from nonlinear and linear decoupling parameters, thereby classifying fluctuation continuation scenarios. A sparse neural network (SNN) oriented to high-dimensional sparse features is constructed to identify historical fluctuation continuation scenarios, and ultra-short-term power forecasting is conducted separately for each scenario. Validation using measured wind speed and power data from three wind farms shows that, compared with baseline models, the proposed model improves root mean square error (RMSE), mean absolute error (MAE), and mean absolute percentage error (MAPE) by at least 1.46%, 2.44%, and 14.67%, respectively, demonstrating superior accuracy and stability. The method addresses the limitations of signal decomposition techniques that lack physical interpretability and are sensitive to hyperparameters, and overcomes the high-dimensional sparsity challenges faced by traditional scenario identification models.
Multi-Classifier Open Adversarial Network for Rolling Bearing Fault Diagnosis in Wind Turbine Generator Systems
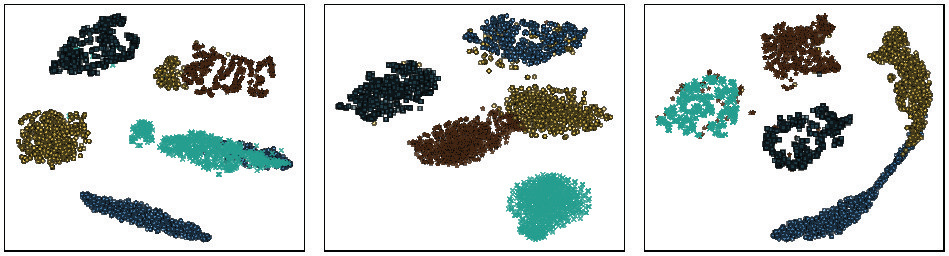
Rolling bearings in wind turbine generator systems operate under variable speed and load conditions that induce significant data distribution shifts between training and field data, while unknown fault modes absent from the source domain are frequently misclassified as known classes. This study proposes a multi-classifier open adversarial network (MCOAN) for open-set fault diagnosis. Within an adversarial domain adaptation framework, a K-way classifier and an additional K+1-way one-vs-all classifier independently estimate target-sample similarity to the source domain. These similarity scores drive a dynamic weighting mechanism that adaptively reweights target samples during open-set adversarial training and supplies per-sample dynamic thresholds for known/unknown discrimination, thereby promoting cross-domain alignment of shared-class features while suppressing negative transfer from unknown samples. A non-adversarial domain classifier is introduced to stabilize dynamic weight estimation. Validation on two datasets demonstrates high-precision shared-class distribution alignment and unknown-class recognition with favorable robustness. The method removes reliance on empirically preset thresholds that plague conventional open-set back-propagation approaches, where a fixed threshold of 0.5 in the binary cross-entropy adversarial loss provides no per-sample adaptivity. By coupling K-way and K+1-way similarity estimates, MCOAN achieves simultaneous known-class alignment and unknown-class separation without prior knowledge of the unknown-class cardinality, addressing a persistent bottleneck in wind turbine drivetrain condition monitoring where unanticipated bearing failure modes emerge under field conditions.
Unsupervised Automated Identification Method for Abnormal States of Wind Turbine Gearboxes
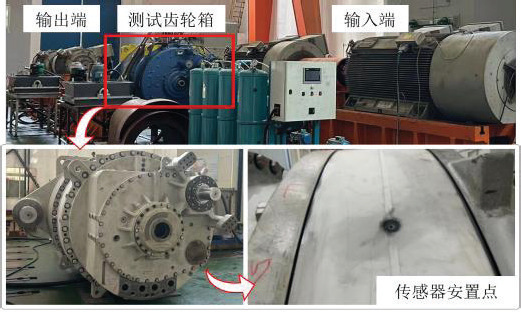
Addressing the scarcity of labeled data for training classification models in wind turbine planetary gearbox anomaly identification, this study proposes an unsupervised automated detection method. Log Mel-band energy features are extracted from raw vibration signals and fed into an unsupervised anomaly recognition model centered on a U-net autoencoder. A health-state threshold is established based on reconstruction error between model input and output, enabling anomaly identification. The method is validated using factory gearbox test data and operational data from a wind farm in Yangtouya, Shanxi. For factory gearboxes, dual validation is performed using a spectrum amplitude modulation-based signal processing method. Results demonstrate that the proposed method achieves 93.34% recognition accuracy on both factory and wind farm test sets, confirming its capability to automatically and correctly separate abnormal wind turbine gearboxes. The approach eliminates reliance on labeled fault data, offering a scalable solution for full-lifecycle health monitoring, from factory acceptance testing to in-service early anomaly detection, adaptable across different operating conditions and turbine models.
Improved Adaptive Super-Twisting Sliding Mode Control for Permanent Magnet Synchronous Motors
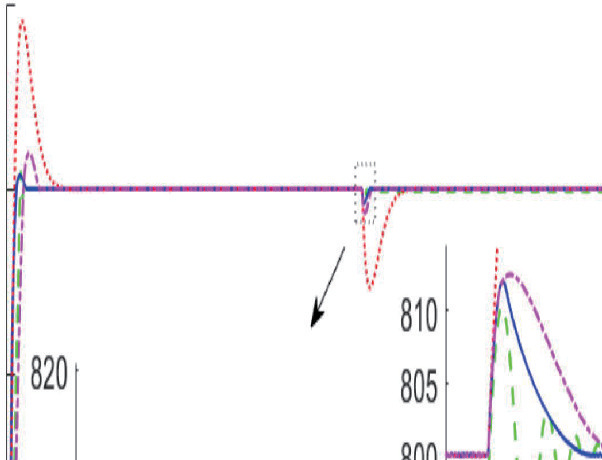
Adaptive super-twisting sliding mode control (ASTSMC) for permanent magnet synchronous motors (PMSM) suffers from prolonged convergence and insufficient disturbance rejection under complex operating conditions. This paper proposes an improved ASTSMC incorporating a fixed-time disturbance observer (FTDO). A power term is introduced into the adaptive super-twisting controller to accelerate convergence far from the origin, while the discontinuous sign function is replaced by a continuous h(s) function to mitigate chattering. The FTDO ensures disturbance estimation converges within a fixed time independent of initial states, overcoming the limitations of traditional and finite-time observers. The estimated disturbance is fed forward to the sliding mode controller for compensation, enhancing robustness. The FTDO design is based on an auxiliary state variable z and its derivative, with error dynamics analyzed via Lyapunov stability. Comparative simulations against conventional disturbance observers and sliding mode controllers validate the proposed strategy. The results demonstrate shorter convergence time, improved dynamic performance, and superior disturbance rejection, making the approach suitable for high-performance servo systems. The method addresses the critical need for robust, fast-response control in electric vehicles, rail transit, and aerospace applications where PMSM drives face significant uncertainties and external disturbances.