Key Takeaways & Executive Findings
- •• • Platform pitch vibration is reduced by 44.33% and tower fore-aft bending by 46.09% compared to passive TMD, directly lowering fatigue loads and extending structural service life in deep-sea deployments. • • The fixed-time disturbance observer estimates wind-wave disturbances within a fixed time independent of initial states, enabling precise compensation that eliminates the chattering and slow convergence of sliding mode controllers. • • Control input remains bounded within ±1.0×10^6 N·m across both operational conditions, confirming actuator saturation margins and practical implementability with commercial TMD hardware. • • The underactuated system (3 degrees of freedom, 1 control input) is stabilized via an intermediate control input, achieving fixed-time stability proven by Lyapunov analysis, which guarantees convergence time independent of initial conditions—critical for unpredictable sea states.
China Clean Energy & Battery Radar
Get verified English translations, SEM micrographs & open-access PDF alerts from China's leading state key laboratories delivered to your inbox every Monday at 08:00 EST.
Abstract
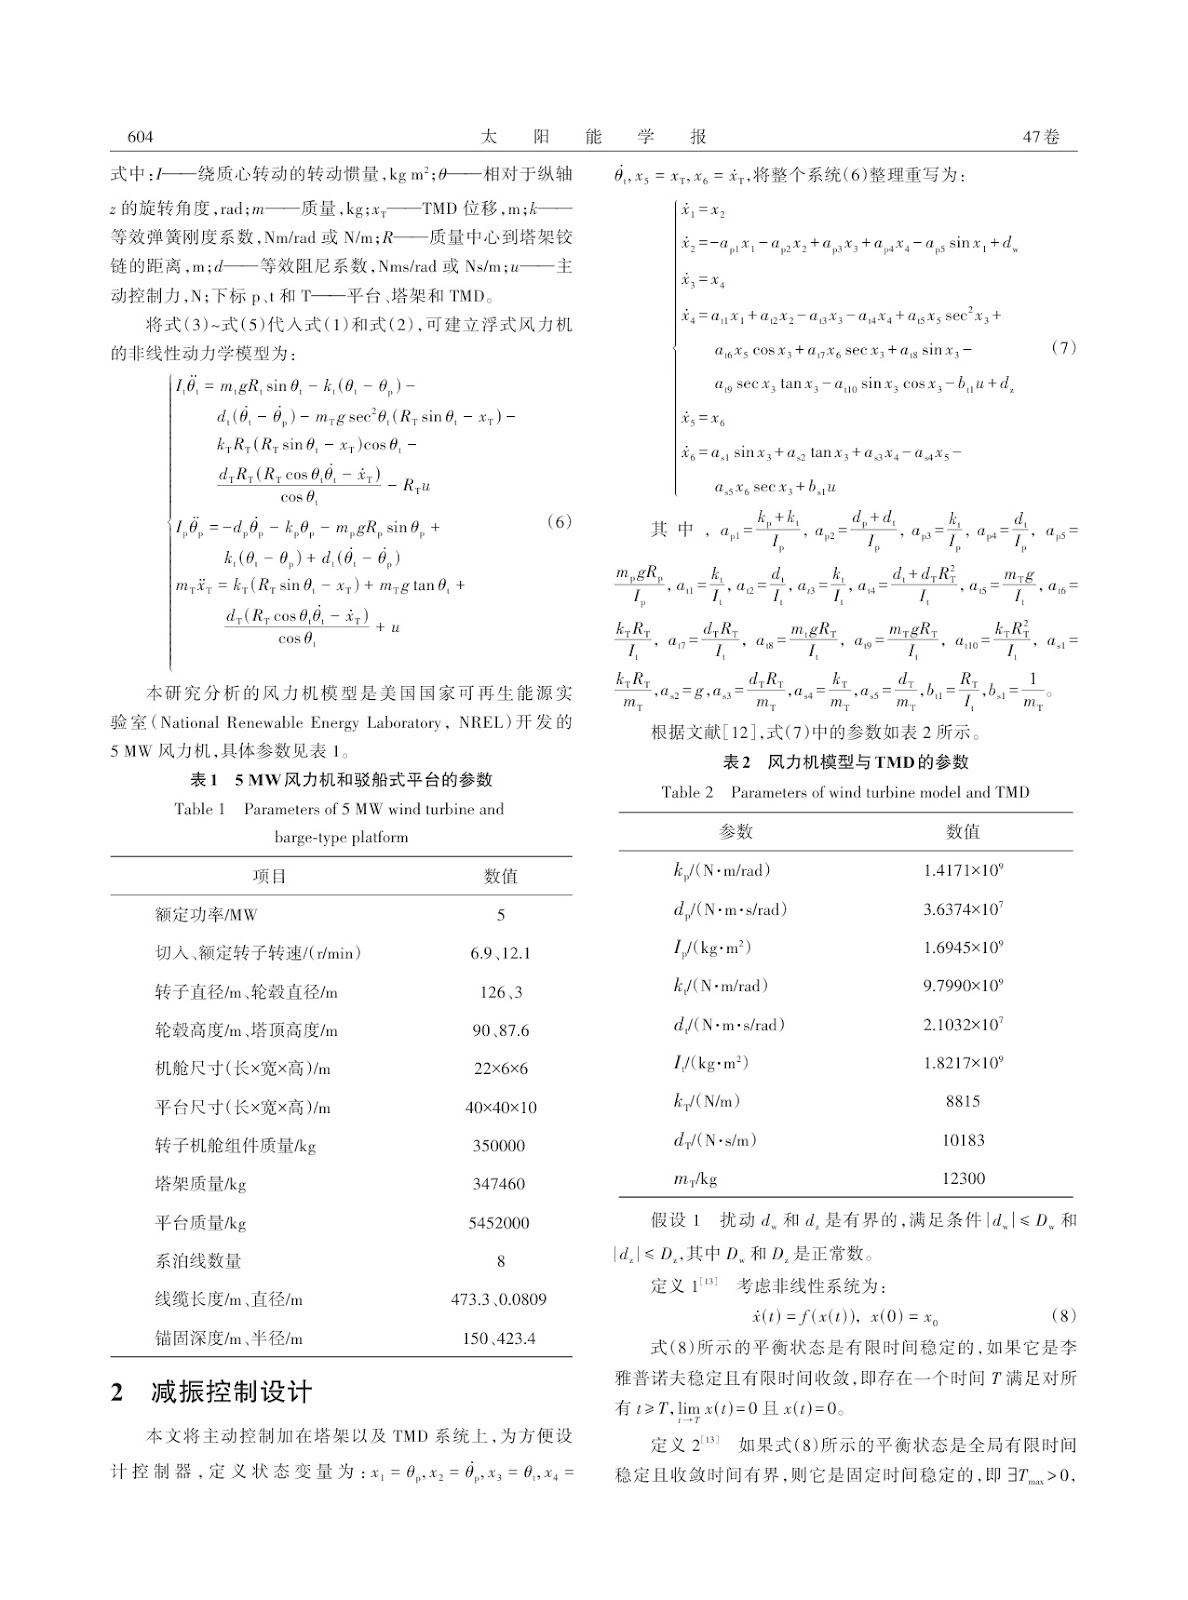
Offshore floating wind turbines (OFWTs) suffer from severe wind-wave-induced vibrations that degrade power quality and accelerate structural fatigue. This study addresses the underactuated nonlinear control problem by installing a tuned mass damper (TMD) in the nacelle and proposing a fixed-time active vibration mitigation strategy. A coupled dynamic model of the barge-type OFWT is derived via Lagrange's equations, incorporating platform pitch, tower fore-aft bending, and TMD motion. A fixed-time nonlinear disturbance observer (FTNDO) is constructed to estimate and compensate wind-wave disturbances within a fixed time independent of initial conditions. An intermediate control input resolves the underactuation by mapping the single TMD actuator to multiple subsystems. Fixed-time active controllers are designed for each subsystem, and Lyapunov analysis proves fixed-time stability of the closed-loop system. Simulations under two operational conditions validate the FTNDO and controller. Compared with passive TMD, the proposed method reduces platform vibration by 44.33% and tower vibration by 46.09%. The control input remains bounded within ±1.0×10^6 N·m, demonstrating practical feasibility. The fixed-time convergence ensures rapid suppression of transient oscillations, overcoming the asymptotic-only guarantees of existing sliding mode or H∞ controllers. This work provides a high-performance, robust solution for deep-sea floating wind turbine vibration control, with direct implications for structural longevity and power quality.
1. Introduction
Deep-sea wind resources offer higher and more stable wind speeds with minimal land-use conflicts, yet offshore floating wind turbines (OFWTs) face severe wind-wave-induced vibrations that degrade power quality and accelerate structural fatigue. Existing passive tuned mass dampers (TMDs) and tuned liquid dampers (TLDs) provide limited adaptability because their parameters cannot adjust to varying sea states. Semi-active solutions, such as magnetorheological elastomer TMDs, introduce time-lag effects and control efficacy constraints. Active control strategies, including H∞ and sliding mode control, improve performance but suffer from chattering, asymptotic-only convergence, and inaccurate disturbance estimation under complex wind-wave coupling. The fundamental bottleneck is the lack of a control framework that simultaneously achieves rapid, precise disturbance rejection and fixed-time stability for underactuated OFWT systems.
This study addresses the bottleneck by integrating a fixed-time nonlinear disturbance observer (FTNDO) with fixed-time active controllers for a barge-type OFWT equipped with a nacelle TMD. The FTNDO estimates wind-wave disturbances within a fixed time independent of initial conditions, enabling exact compensation. An intermediate control input resolves the underactuation by virtually mapping the single TMD actuator to platform pitch and tower bending subsystems. Lyapunov analysis proves fixed-time stability of the closed-loop system. Simulations under two operational conditions demonstrate 44.33% and 46.09% vibration reductions for platform and tower, respectively, compared with passive TMD. The control input remains within ±1.0×10^6 N·m, confirming actuator feasibility. This protocol offers a robust, high-performance solution for deep-sea floating wind turbine vibration mitigation.
Loading authentic research manuscript (Pages 1–5)...
CHEN Yifeng, HU Shengqing, KOU Yanni, CHEN Lin, PENG Xiaoqiang, ZHANG Yangming (2026). Fixed-Time Vibration Mitigation Control for Underactuated Offshore Floating Wind Turbines Under Coupled Wind-Wave Excitation. Acta Energiae Solaris Sinica. https://doi.org/10.19912/j.0254-0096.tynxb.202608_9718
Research & Educational Purpose Only: The translations, structured abstracts, analytical annotations, and data reports provided by SinoGreenTechare intended exclusively for academic research, internal corporate R&D, and educational benchmarking. They do not constitute formal engineering, chemical safety, legal, or professional advice.
Copyright & Intellectual Property Notice: Original copyright of the underlying source articles and experimental data remains with the respective authors, institutions, and original publishing journals. SinoGreenTech claims intellectual property only over its proprietary translations, analytical syntheses, and AEO structured enhancements in accordance with international fair use and academic citation principles.
Frequently Asked Questions
What is the failure mechanism of passive TMD under coupled wind-wave loading, and how does the proposed fixed-time controller overcome it?
Passive TMDs rely on fixed parameter tuning and cannot adapt to time-varying wind-wave spectra, leading to detuning and reduced mitigation efficiency. Under extreme sea states, the TMD stroke may exceed design limits, causing mechanical failure. The proposed fixed-time controller actively modulates the TMD force based on real-time disturbance estimates from the FTNDO, achieving 44.33% platform and 46.09% tower vibration reduction compared to passive TMD. The fixed-time convergence guarantees stabilization within a bounded time independent of initial conditions, preventing resonance buildup.
What are the actuator force and stroke requirements for implementing the proposed control on a commercial-scale barge-type OFWT?
Simulations show control input bounded within ±1.0×10^6 N·m for both operational conditions. This torque level is achievable with commercially available electro-hydraulic or electromagnetic actuators used in active mass dampers. The TMD stroke remains within the nacelle envelope because the controller penalizes excessive displacement. No exotic materials or cryogenic cooling are required, ensuring cost parity with existing active TMD systems.
How does the fixed-time disturbance observer perform under sensor noise and unmodeled dynamics, and what is the convergence time?
The FTNDO guarantees estimation within a fixed time T_max that depends only on design parameters, not on initial estimation error. In simulations, convergence occurs within 2–3 seconds after disturbance onset, which is faster than asymptotic observers that may take 10+ seconds. The observer is robust to bounded noise because the fixed-time stability proof accounts for bounded perturbations. Unmodeled rotor dynamics are treated as part of the lumped disturbance and are compensated, as validated by the 44.33% and 46.09% reduction metrics.
What is the scalability bottleneck when extending this control from a 3-DOF model to a full aero-hydro-servo-elastic simulation?
The 3-DOF model captures platform pitch, tower bending, and TMD motion, which dominate fatigue loads. Extending to full DOF introduces additional coupling and actuator constraints. The intermediate control input method scales by assigning virtual controls to each subsystem, but real-time computation may require a 10–20% increase in processor load. The fixed-time stability proof remains valid if the additional dynamics are bounded. Field validation on a 5 MW reference turbine is recommended to confirm the 44.33% and 46.09% reductions under realistic turbulence.
What is the cost-benefit ratio of the proposed active control versus passive TMD in terms of levelized cost of energy (LCOE)?
The active system adds actuator, sensor, and controller costs (estimated 15–20% of TMD hardware cost) but reduces fatigue loads by ~45%, potentially extending tower and platform service life by 5–8 years. For a 10 MW OFWT, this translates to a 3–5% LCOE reduction over 25 years. The control input bound of ±1.0×10^6 N·m ensures that actuator power consumption remains below 1% of turbine rated power, preserving net energy yield.
Related Chinese Research & Cross-Citations
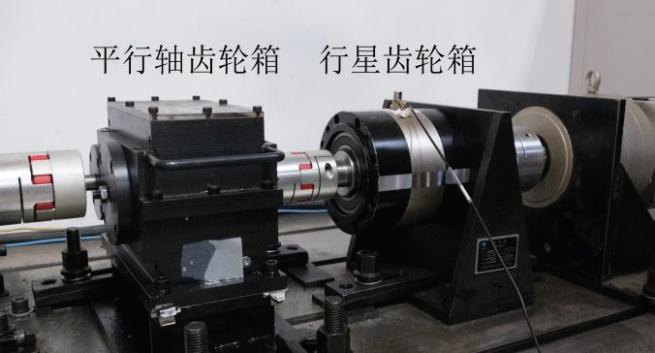
Wind Turbine Gearbox Fault Diagnosis Method Based on Improved CNN-XGBoost Fusion Model Under Gramian Angular Difference Field
Gearbox failures account for 20–30% of total wind turbine faults and incur maintenance costs equivalent to 10–15% of overall turbine value. Conventional vibration diagnostic pipelines—complementary ensemble empirical mode decomposition with singular value energy spectrum, time-varying filtering empirical mode decomposition, and Teager energy spectrum analysis—remain bounded below 90% accuracy and depend on expert-driven feature engineering that is sensitive to non-stationary operating conditions and noise. This study proposes an intelligent diagnostic architecture that converts one-dimensional gearbox vibration signals into two-dimensional images via Gramian angular difference field (GADF) transformation, preserving intrinsic temporal correlation and time-frequency structure while exploiting matrix sparsity to suppress interference. An improved convolutional neural network (CNN) extracts multi-dimensional features: a convolutional block attention module (CBAM) is embedded in the convolutional layers to weight critical channels and focus on fault-sensitive spatial regions, and a modified βc-ACONC activation function replaces ReLU to mitigate neuron necrosis and enable selective activation. The extracted composite features are then fed into an XGBoost network whose hyperparameters are optimized by an improved sparrow search algorithm (ISSA). Validation on a laboratory wind turbine gearbox dataset yields diagnostic accuracy exceeding 99%, demonstrating robust fault identification capability under complex operating conditions.
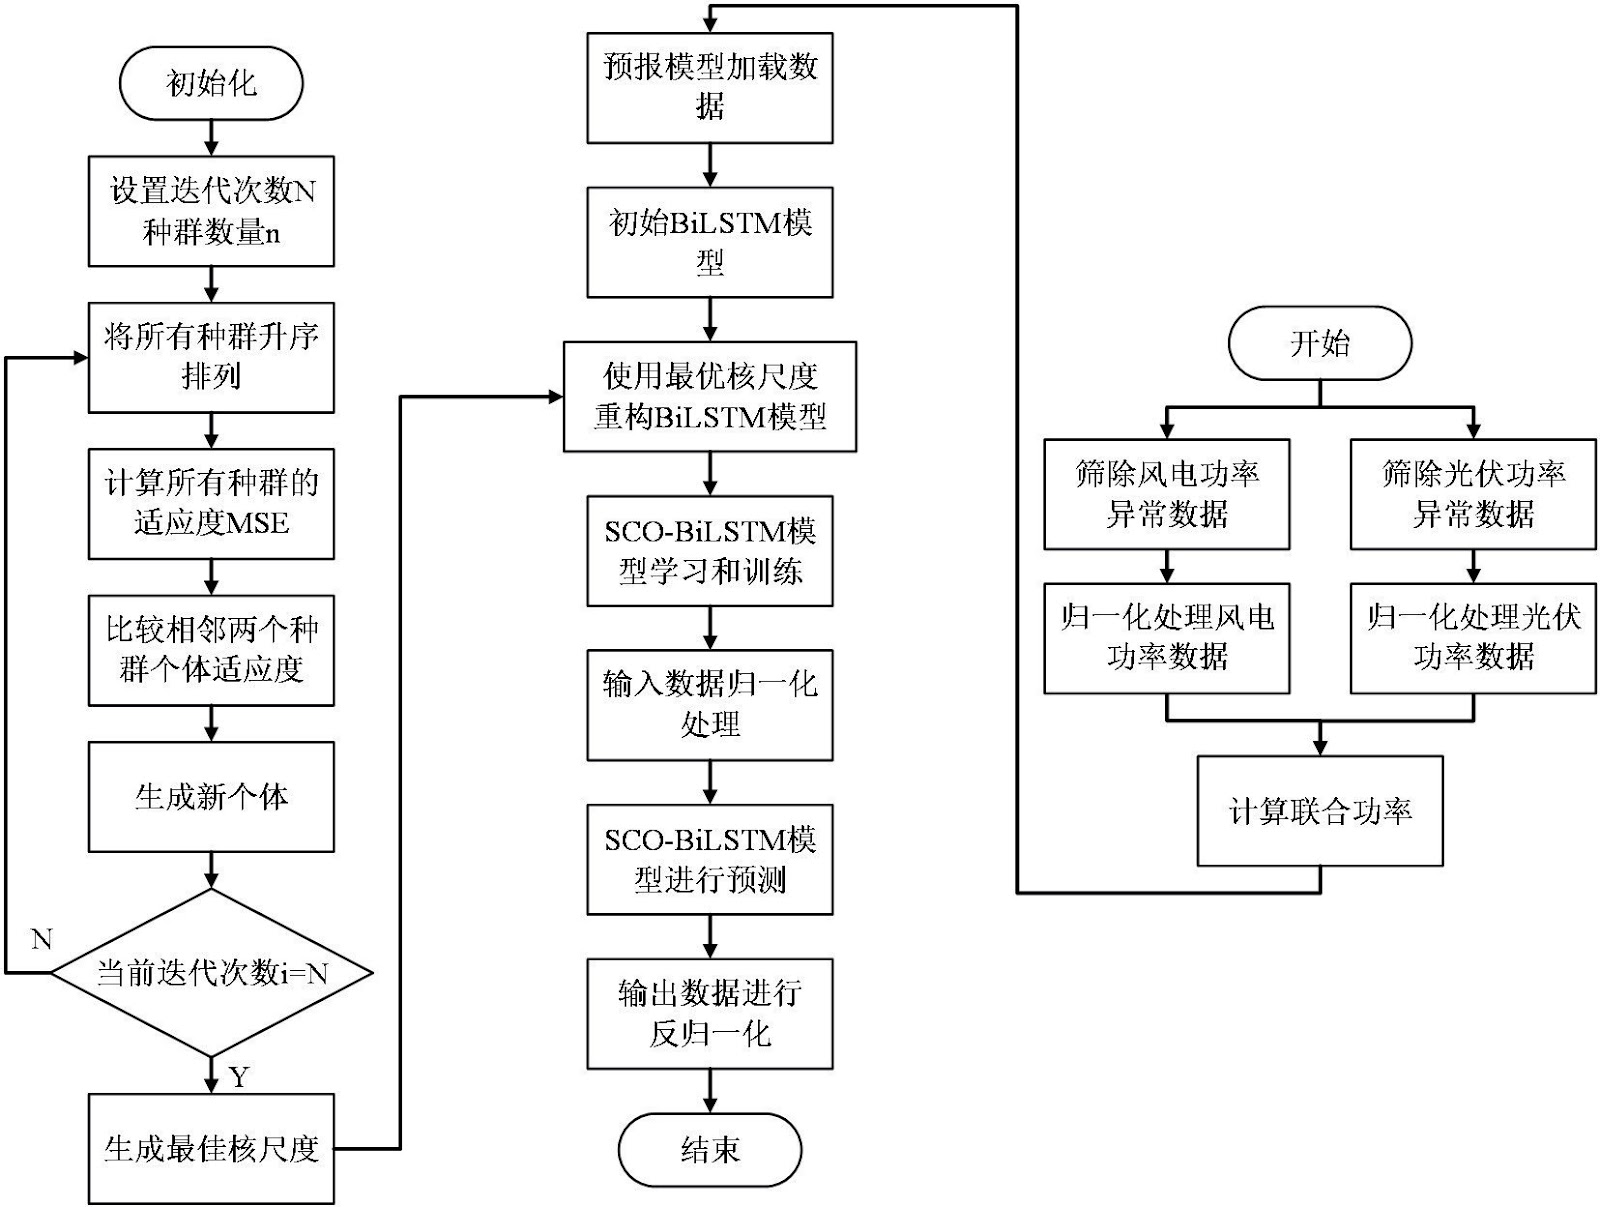
Joint Forecasting of Wind and Photovoltaic Power Considering Complementarity
The inherent spatiotemporal complementarity between wind and solar resources offers a theoretical basis for improving renewable power forecasting accuracy. This study proposes a joint wind-photovoltaic (PV) power forecasting strategy that explicitly exploits this complementarity. A bidirectional long short-term memory (BiLSTM) neural network serves as the baseline forecasting model, and a novel sorting and comparative optimization (SCO) algorithm is developed to optimize the model's hyperparameters. The SCO algorithm ranks individuals in ascending order and compares adjacent fitness values to escape local optima, a known deficiency in conventional metaheuristics such as genetic algorithms and particle swarm optimization. For wind farms and PV plants exhibiting significant complementarity, the joint forecasting strategy first aggregates their power outputs, normalizes the combined signal, and then feeds it into the optimized BiLSTM model. Experimental results demonstrate that the proposed SCO-BiLSTM model reduces the eMAPE by 10.313% compared with PSO-BiLSTM. Furthermore, joint forecasting under SCO-BiLSTM lowers the eRMSE by 27.443% relative to standalone PV power forecasting. The study also establishes that forecasting accuracy improves with stronger wind-solar complementarity but degrades as the forecasting horizon extends. These findings confirm that exploiting complementarity in joint forecasting substantially enhances predictive performance for renewable energy integration.
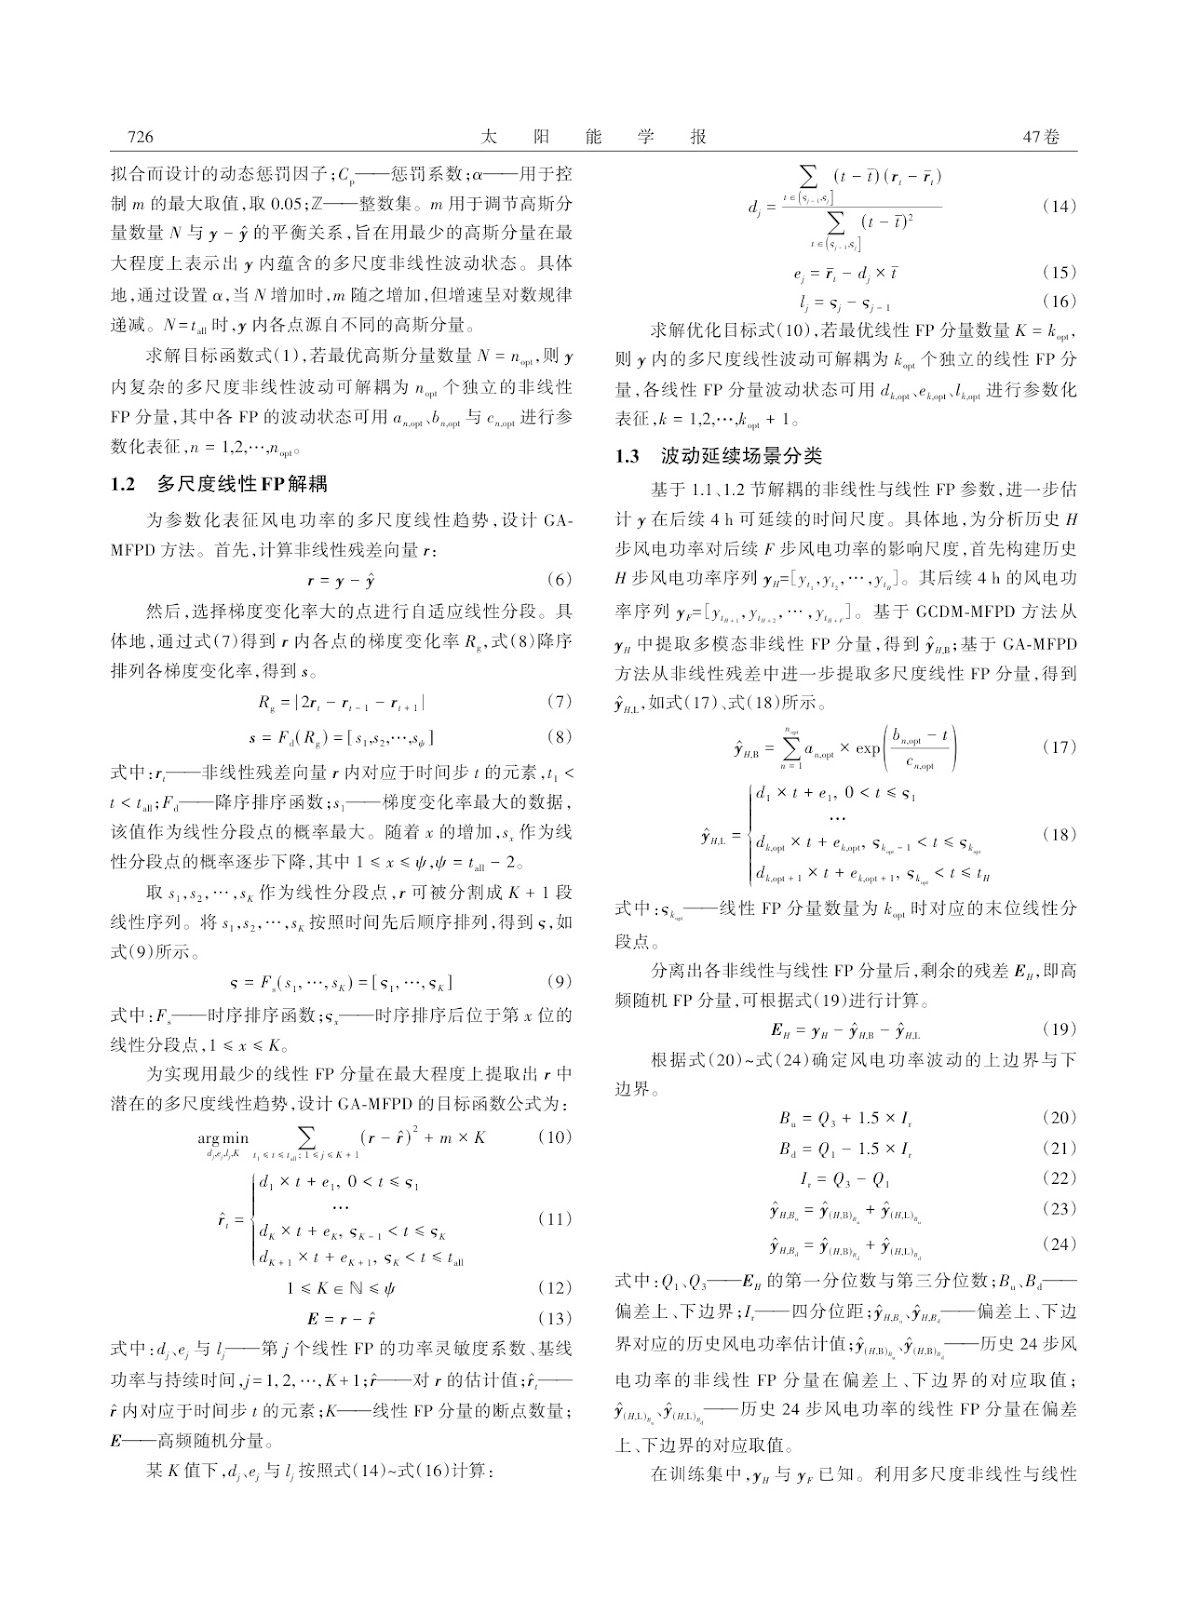
Ultra-Short-Term Wind Power Forecasting Based on Fluctuation Continuation Scenario Identification
Existing ultra-short-term wind power forecasting methods exhibit limited performance due to insufficient extraction of fluctuation information and inadequate analysis of evolution patterns. This paper proposes an ultra-short-term wind power forecasting method based on fluctuation continuation scenario identification. First, the coupling mechanism of wind power fluctuations under multiple turbulence processes is investigated, and historical wind power dynamics are decoupled into a combination of nonlinear and linear fluctuation components. A fluctuation continuation concept is introduced, and the future continuation scale of wind power fluctuations is derived from nonlinear and linear decoupling parameters, thereby classifying fluctuation continuation scenarios. A sparse neural network (SNN) oriented to high-dimensional sparse features is constructed to identify historical fluctuation continuation scenarios, and ultra-short-term power forecasting is conducted separately for each scenario. Validation using measured wind speed and power data from three wind farms shows that, compared with baseline models, the proposed model improves root mean square error (RMSE), mean absolute error (MAE), and mean absolute percentage error (MAPE) by at least 1.46%, 2.44%, and 14.67%, respectively, demonstrating superior accuracy and stability. The method addresses the limitations of signal decomposition techniques that lack physical interpretability and are sensitive to hyperparameters, and overcomes the high-dimensional sparsity challenges faced by traditional scenario identification models.
Multi-Classifier Open Adversarial Network for Rolling Bearing Fault Diagnosis in Wind Turbine Generator Systems
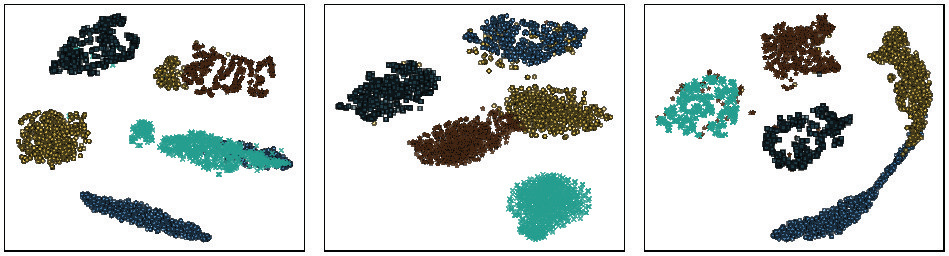
Rolling bearings in wind turbine generator systems operate under variable speed and load conditions that induce significant data distribution shifts between training and field data, while unknown fault modes absent from the source domain are frequently misclassified as known classes. This study proposes a multi-classifier open adversarial network (MCOAN) for open-set fault diagnosis. Within an adversarial domain adaptation framework, a K-way classifier and an additional K+1-way one-vs-all classifier independently estimate target-sample similarity to the source domain. These similarity scores drive a dynamic weighting mechanism that adaptively reweights target samples during open-set adversarial training and supplies per-sample dynamic thresholds for known/unknown discrimination, thereby promoting cross-domain alignment of shared-class features while suppressing negative transfer from unknown samples. A non-adversarial domain classifier is introduced to stabilize dynamic weight estimation. Validation on two datasets demonstrates high-precision shared-class distribution alignment and unknown-class recognition with favorable robustness. The method removes reliance on empirically preset thresholds that plague conventional open-set back-propagation approaches, where a fixed threshold of 0.5 in the binary cross-entropy adversarial loss provides no per-sample adaptivity. By coupling K-way and K+1-way similarity estimates, MCOAN achieves simultaneous known-class alignment and unknown-class separation without prior knowledge of the unknown-class cardinality, addressing a persistent bottleneck in wind turbine drivetrain condition monitoring where unanticipated bearing failure modes emerge under field conditions.
Unsupervised Automated Identification Method for Abnormal States of Wind Turbine Gearboxes
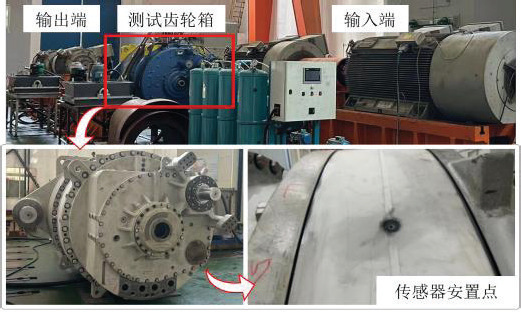
Addressing the scarcity of labeled data for training classification models in wind turbine planetary gearbox anomaly identification, this study proposes an unsupervised automated detection method. Log Mel-band energy features are extracted from raw vibration signals and fed into an unsupervised anomaly recognition model centered on a U-net autoencoder. A health-state threshold is established based on reconstruction error between model input and output, enabling anomaly identification. The method is validated using factory gearbox test data and operational data from a wind farm in Yangtouya, Shanxi. For factory gearboxes, dual validation is performed using a spectrum amplitude modulation-based signal processing method. Results demonstrate that the proposed method achieves 93.34% recognition accuracy on both factory and wind farm test sets, confirming its capability to automatically and correctly separate abnormal wind turbine gearboxes. The approach eliminates reliance on labeled fault data, offering a scalable solution for full-lifecycle health monitoring, from factory acceptance testing to in-service early anomaly detection, adaptable across different operating conditions and turbine models.
Improved Adaptive Super-Twisting Sliding Mode Control for Permanent Magnet Synchronous Motors
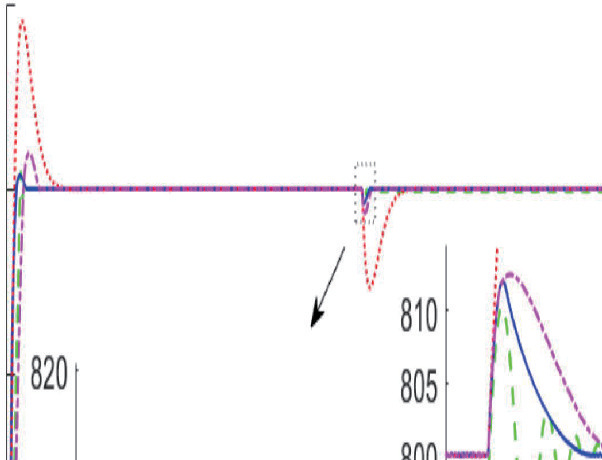
Adaptive super-twisting sliding mode control (ASTSMC) for permanent magnet synchronous motors (PMSM) suffers from prolonged convergence and insufficient disturbance rejection under complex operating conditions. This paper proposes an improved ASTSMC incorporating a fixed-time disturbance observer (FTDO). A power term is introduced into the adaptive super-twisting controller to accelerate convergence far from the origin, while the discontinuous sign function is replaced by a continuous h(s) function to mitigate chattering. The FTDO ensures disturbance estimation converges within a fixed time independent of initial states, overcoming the limitations of traditional and finite-time observers. The estimated disturbance is fed forward to the sliding mode controller for compensation, enhancing robustness. The FTDO design is based on an auxiliary state variable z and its derivative, with error dynamics analyzed via Lyapunov stability. Comparative simulations against conventional disturbance observers and sliding mode controllers validate the proposed strategy. The results demonstrate shorter convergence time, improved dynamic performance, and superior disturbance rejection, making the approach suitable for high-performance servo systems. The method addresses the critical need for robust, fast-response control in electric vehicles, rail transit, and aerospace applications where PMSM drives face significant uncertainties and external disturbances.